AmazingHand
A 400 g four-finger hand with all eight servos inside the hand, so no cables run to a forearm.
Project documentation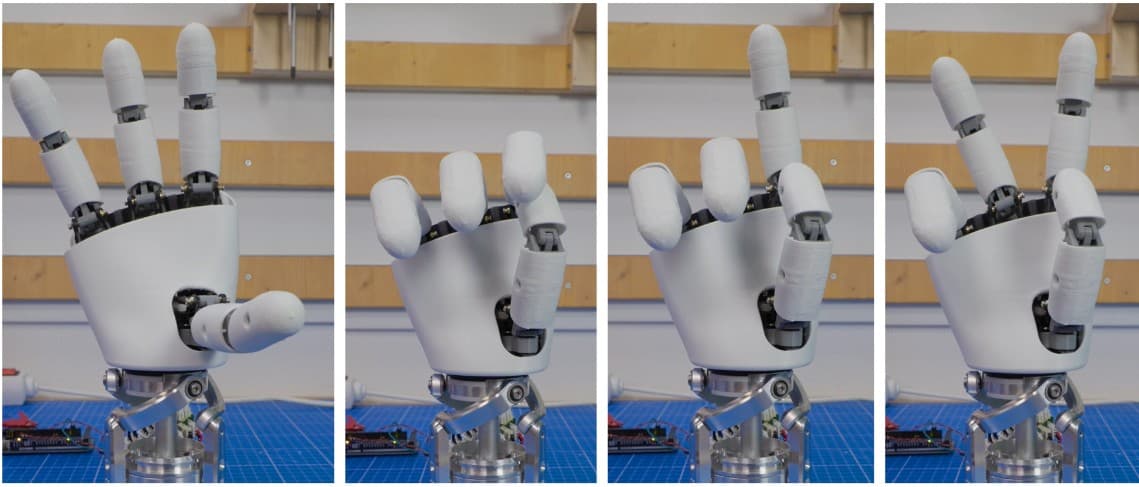
Before you build
Five answers, each linked to its source
What does it cost?
Under €200hand, before controller
Under €200 for the hand. Add the controller you pick: a Waveshare serial bus driver, or an Arduino with a Feetech TTL Linker. README
Can I sell what I build?
Yes, with creditCommercial use OK, with credit
Hardware CC BY 4.0 · Software Apache-2.0. Licensing source
What’s open?
5 of 6CAD: AvailableBOM: AvailablePCB: Off-the-shelf partCode: AvailableSim: AvailableGuide: Available
PCB off-the-shelf. All six files
Is it maintained?
Quiet
Latest activity Apr 3, 2026 · 21 commits in the last 52 weeks · 5 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
A 400 g, 3D-printed humanoid hand with four fingers. Two small servos drive each finger through a parallel mechanism, and all eight sit inside the hand, so no cables run to a forearm. The wrist interface fits Pollen’s Reachy 2 and can be adapted to other arms.
Hardware
- Actuators
- 8 · SCS0009 servos README
- Build
- 3D-printed · flexible shells Documentation
- Degrees of freedom
- 8: two per finger, four fingers README
- Weight
- 400 g README
- Actuators
- Feetech SCS0009 micro servos, two per finger in a parallel mechanism README
- Servo feedback
- Position, torque and temperature feedback; torque on/off README
- Mount
- Designed for Reachy 2’s wrist; adaptable to other arms README
- Maturity
- Not yet tested on long, complex grasping tasks, per the maker README
Building it
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STL and STEP files, plus a public Onshape document | CC BY 4.0 | cad/ |
| Bill of materials | Available | Google Sheet, with a tab for the 3D-printed parts | Not documented | BOM sheet |
| Electronics | Off-the-shelf part | Off-the-shelf bus driver or Arduino; a custom PCB is on the to-do list | — | README |
| Code | Available | Python and Arduino demos, plus kinematics examples | Apache-2.0 | README |
| Simulation model | Available | MuJoCo MJCF model | Apache-2.0 | AHSimulation |
| Assembly guide | Available | Assembly guide and 3D-printing tips as PDFs | Not documented | Assembly PDF |
03 / Know before you build
Can you sell it?
Yes, with creditCommercial use OK, with credit
The mechanical design is CC BY 4.0 and the code is Apache-2.0. Both allow commercial use, provided you credit Pollen Robotics and keep the license notices.
- Hardware
- CC BY 4.0
- Software
- Apache-2.0
04 / The upstream project
Is it maintained?
QuietLatest activity Apr 3, 2026, 201 days before the snapshot
- Stars
- 2,462
- Forks
- 288
- Contributors
- 5
- Latest release
- v1.0 · Apr 1, 2026
An “Enhanced” version is developed on a separate branch, which these default-branch numbers don’t include.
Snapshot captured Oct 21, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
2 sellers listed by the maker. No affiliate links or paid placement.
MAKER’S COST
Under €200
hand, before controller
Under €200 for the hand. Add the controller you pick: a Waveshare serial bus driver, or an Arduino with a Feetech TTL Linker.
README06 / Side by side
Compare with other hands & grippers.
The three hands & grippers with the closest documented maker’s cost. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| AmazingHandThis robotPollen Robotics | Under €200hand, before controller | 5 of 6 | Yes, with creditHW CC BY 4.0 · SW Apache-2.0 | PythonArduinoMuJoCo | QuietApr 3, 2026 | 2,462 |
| Aero Hand OpenChestnut Robotics | $314complete kit | 6 of 6 | NoHW CC BY-NC-SA 4.0 · SW Apache-2.0 | ROS 2MuJoCoPython | ActiveSep 15, 2026 | 1,054 |
| YAM-UMIYosub Shin | About $79per gripper | 3 of 6 | YesHW MIT · SW MIT | Not documented | Not documented | — |
| Pinc'Openpollen-robotics | About €25standalone PincOpen gripper BOM | 3 of 6 | Yes, with creditHW CC BY-SA 4.0 · SW CC-BY-SA-4.0 | LeRobotPython | Not documented | — |
| This robotAmazingHand | Aero Hand Open | YAM-UMI |
|---|---|---|
| Cost | ||
| Under €200 | $314 | About $79 |
| Can I sell it? | ||
| Yes, with credit | No | Yes |
| Open files | ||
| 5 of 6 | 6 of 6 | 3 of 6 |
| Runs on | ||
| Python, Arduino, MuJoCo | ROS 2, MuJoCo, Python, ESP32 | Not documented |
| Maintained | ||
| QuietApr 3, 2026 | ActiveSep 15, 2026 | Not documented |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the tableConnected projects and guides
Keep exploring.
- DESIGNED FORReachy 2 Pollen Robotics’ humanoid; the wrist interface fits its Orbita 3D wrist
- SUCCESSORAmazingHand Enhanced Newer design on its own branch
- FITSSO-101 A community interface mounts the hand on SO-Arm
- COMMUNITYSG90 force-control variant Cheaper SG90 servos with force control
- VIDEOHand-tracking demo YouTube
- GUIDEAssembly guide (PDF) Standalone right hand
07 / Follow the evidence
Open books.
Repository files are pinned to commit 3e82410. Websites and papers are listed with their review dates.
- 01README at commit 3e82410 (license section)Reviewed Oct 21, 2026
- 02LICENSE (Apache-2.0)Reviewed Oct 21, 2026
- 03cad/ folder (STL and STEP)Reviewed Oct 21, 2026
- 04Demo/AHSimulation (MJCF)Reviewed Oct 21, 2026
- 05GitHub API: stars, contributors, commit activityReviewed Oct 21, 2026