D1 Quadruped Robot
D1 is an open-source quadruped with public mechanical models, manufacturing drawings, printable STL parts, and a robot-level BOM.
Project documentation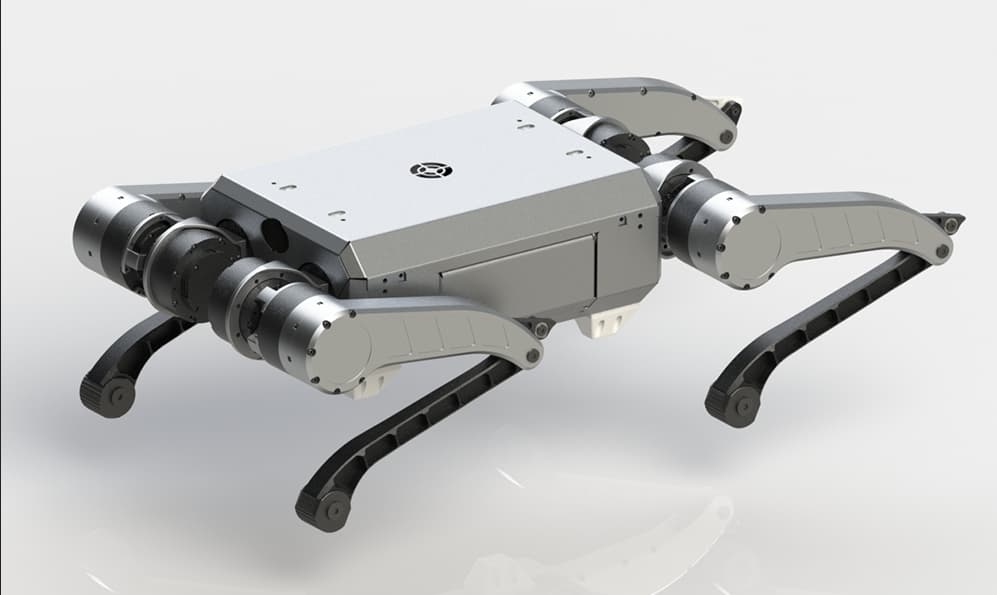
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Yes, with creditCommercial use OK, with credit
Hardware GPL-3.0 · Software GPL-3.0. Licensing source
What’s open?
3 of 6CAD: AvailableBOM: AvailablePCB: AvailableCode: PartialSim: Not documentedGuide: Not documented
Code partial · sim, guide not documented. All six files
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
D1 is an open-source quadruped robot. The repository provides a complete STEP assembly, leg-part STEP models and PDF drawings, printable STL parts, a robot-level BOM, and trunk manufacturing resources covering aluminum parts and tubes, fiberglass parts, and sheet metal.
Hardware
- Actuators
- Not documented Documentation
- Build
- Mixed · Printable STL parts; aluminum, fiberglass, and sheet metal Documentation
Building it
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | Complete STEP assembly, leg-part STEP models, and printable STL parts. | Not documented | mechanical-models-and-drawings/ |
| Bill of materials | Available | Robot-level bill of materials. | Not documented | BOM.xlsx |
| Electronics | Available | EasyEDA Pro project and import notes for the BMS PCB. | Not documented | PCB/ |
| Code | Partial | BMS source project and compiled firmware. | Not documented | Stm32_Code/ |
| Simulation model | Not documented | Not documented | Not documented | No source found |
| Assembly guide | Not documented | Not documented | Not documented | No source found |
03 / Know before you build
Can you sell it?
Yes, with creditCommercial use OK, with credit
The whole repository, design files included, is GPL-3.0. Commercial use is allowed if you keep the maker’s copyright and license notices. Changes you distribute must be shared under the same license.
- Hardware
- GPL-3.0
- Software
- GPL-3.0
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other quadrupeds.
Other quadrupeds in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| D1 Quadruped RobotThis robotNavBotHub | Not documented | 3 of 6 | Yes, with creditHW GPL-3.0 · SW GPL-3.0 | GazeboIsaacMuJoCo | Not documented | — |
| Spot Micro - LeikaRune Harlyk | Not documented | 4 of 6 | YesHW MIT · SW MIT License | ESP32MuJoCo | ActiveOct 29, 2026 | 92 |
| Physical AntOpenmind-Research-Institute | $2,230.61BOM total | 4 of 6 | YesHW MIT · SW MIT | PythonMuJoCo | ActiveOct 29, 2026 | 76 |
| SesameDorian Todd | Not documented | 6 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ESP32ArduinoPython | ActiveOct 15, 2026 | 4,876 |
| This robotD1 Quadruped Robot | Spot Micro - Leika | Physical Ant |
|---|---|---|
| Cost | ||
| Not documented | Not documented | $2,230.61 |
| Can I sell it? | ||
| Yes, with credit | Yes | Yes |
| Open files | ||
| 3 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| Gazebo, Isaac, MuJoCo | ESP32, MuJoCo | Python, MuJoCo |
| Maintained | ||
| Not documented | ActiveOct 29, 2026 | ActiveOct 29, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit 696df69. Websites and papers are listed with their review dates.
- 01README.md at 696df69Reviewed Oct 30, 2026
- 02LICENSE at 696df69Reviewed Oct 30, 2026