ElectroPup
A DIY 3D-printed quadruped with 12 BLDC motors and a Python-coded control system.
Project documentation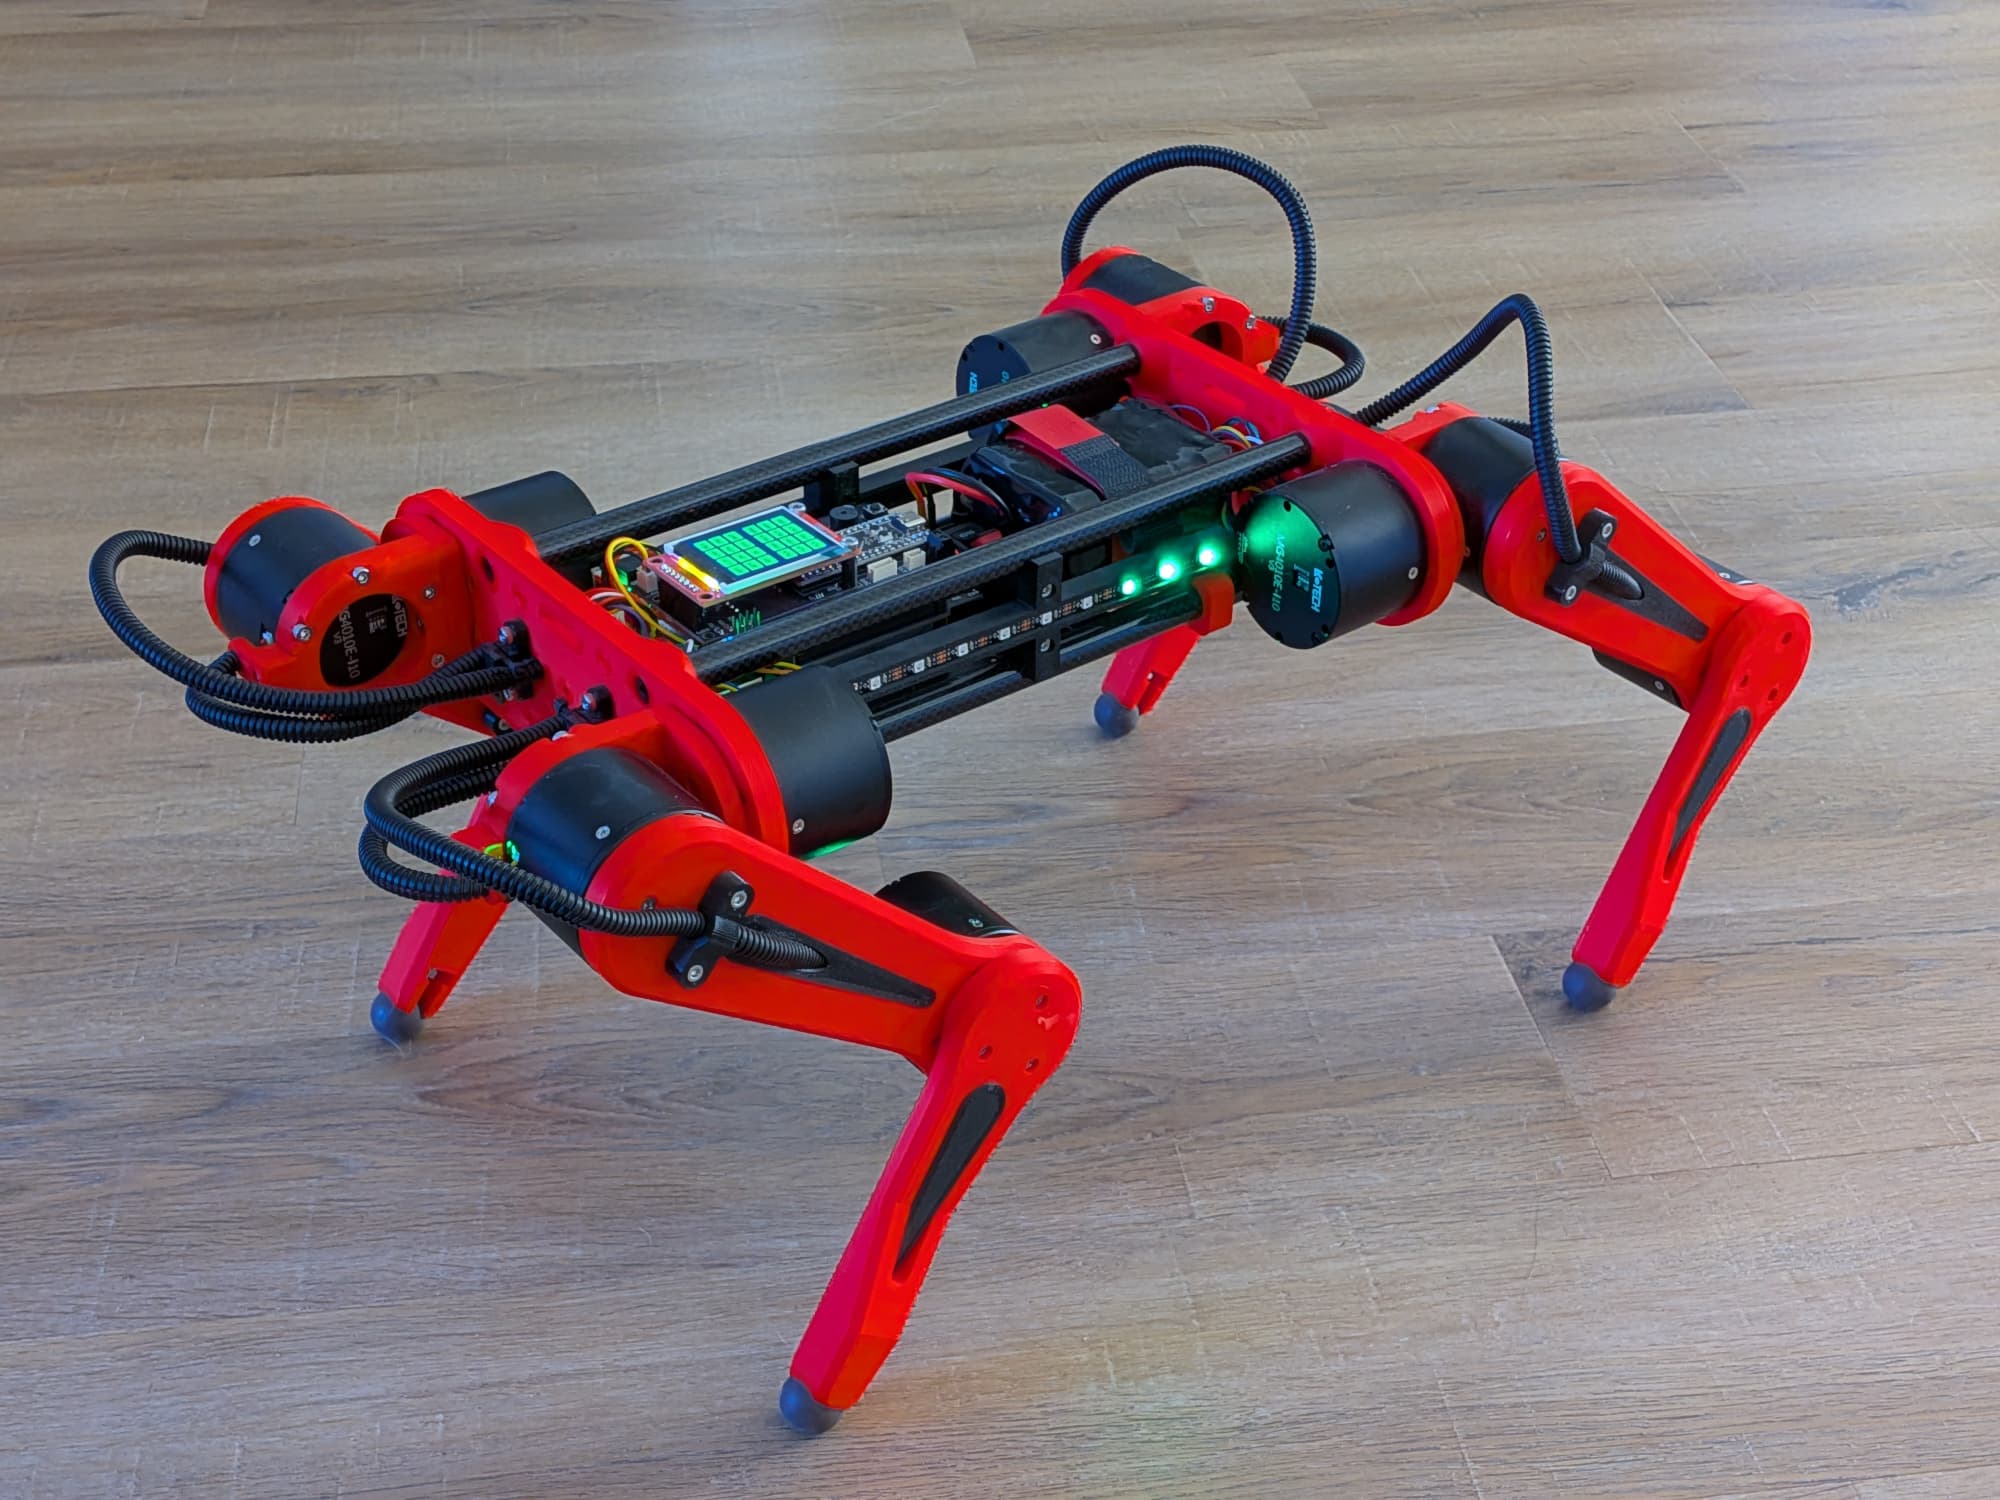
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Check firstCheck before commercial use
Hardware not documented · Software not documented. Licensing source
What’s open?
6 of 6CAD: AvailableBOM: AvailablePCB: AvailableCode: AvailableSim: AvailableGuide: Available
All six available. All six files
What does it run on?
Simulation: MuJoCo simulation is documented; a model file is in src/model. Software
Is it maintained?
Quiet
Latest activity Jul 30, 2026 · main repo last commit Jul 30, 2026 · 28 commits in the last 52 weeks · 1 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
ElectroPup is a 3D-printed quadruped with 12 BLDC motors and a Raspberry Pi 5. Its control system is coded in Python, and its printed parts use PolyMax Tough PLA. The stated robot weight is 4.5 kg.
Hardware
Building it
Software & simulation
- Runs on
- PythonMuJoCoRaspberry Pi
- Control system
- Coded in Python README
- Simulation
- MuJoCo README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STL parts, a STEP assembly, and linked Onshape documents. | Not documented | 3D/ |
| Bill of materials | Available | A bill of materials is listed in the docs directory. | Not documented | bom.ods |
| Electronics | Available | KiCad PCB designs are in the pcbs directory. | Not documented | pcbs/ |
| Code | Available | The control system is coded in Python. | Not documented | src/ |
| Simulation model | Available | MuJoCo simulation is documented; a model file is in src/model. | Not documented | model/ |
| Assembly guide | Available | A setup guide is listed in the docs directory. | Not documented | setup.md |
03 / Know before you build
Can you sell it?
Check firstCheck before commercial use
No license was found for the design files, so no reuse rights are granted. Ask the maker before building anything to sell.
- Hardware
- Not documented
- Software
- Not documented
04 / The upstream project
Is it maintained?
QuietLatest activity Jul 30, 2026, 92 days before the snapshot
The main repository’s last commit was Jul 30, 2026.
- Stars
- 260
- Forks
- 35
- Contributors
- 1
- Latest release
- None recorded
Snapshot captured Oct 30, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other quadrupeds.
Other quadrupeds in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| ElectroPupThis robotreubenstr | Not documented | 6 of 6 | Check firstHW not documented · SW not documented | PythonMuJoCoRaspberry Pi | QuietJul 30, 2026 | 260 |
| Spot Micro - LeikaRune Harlyk | Not documented | 4 of 6 | YesHW MIT · SW MIT License | ESP32MuJoCo | ActiveOct 29, 2026 | 92 |
| Physical AntOpenmind-Research-Institute | $2,230.61BOM total | 4 of 6 | YesHW MIT · SW MIT | PythonMuJoCo | ActiveOct 29, 2026 | 76 |
| SesameDorian Todd | Not documented | 6 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ESP32ArduinoPython | ActiveOct 15, 2026 | 4,876 |
| This robotElectroPup | Spot Micro - Leika | Physical Ant |
|---|---|---|
| Cost | ||
| Not documented | Not documented | $2,230.61 |
| Can I sell it? | ||
| Check first | Yes | Yes |
| Open files | ||
| 6 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| Python, MuJoCo, Raspberry Pi | ESP32, MuJoCo | Python, MuJoCo |
| Maintained | ||
| QuietJul 30, 2026 | ActiveOct 29, 2026 | ActiveOct 29, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit a4f4720. Websites and papers are listed with their review dates.
- 01README.md at a4f4720Reviewed Oct 30, 2026