JPL Open Source Rover
A build-it-yourself model of JPL’s six-wheel Mars rovers, made from off-the-shelf aluminium parts.
Project documentation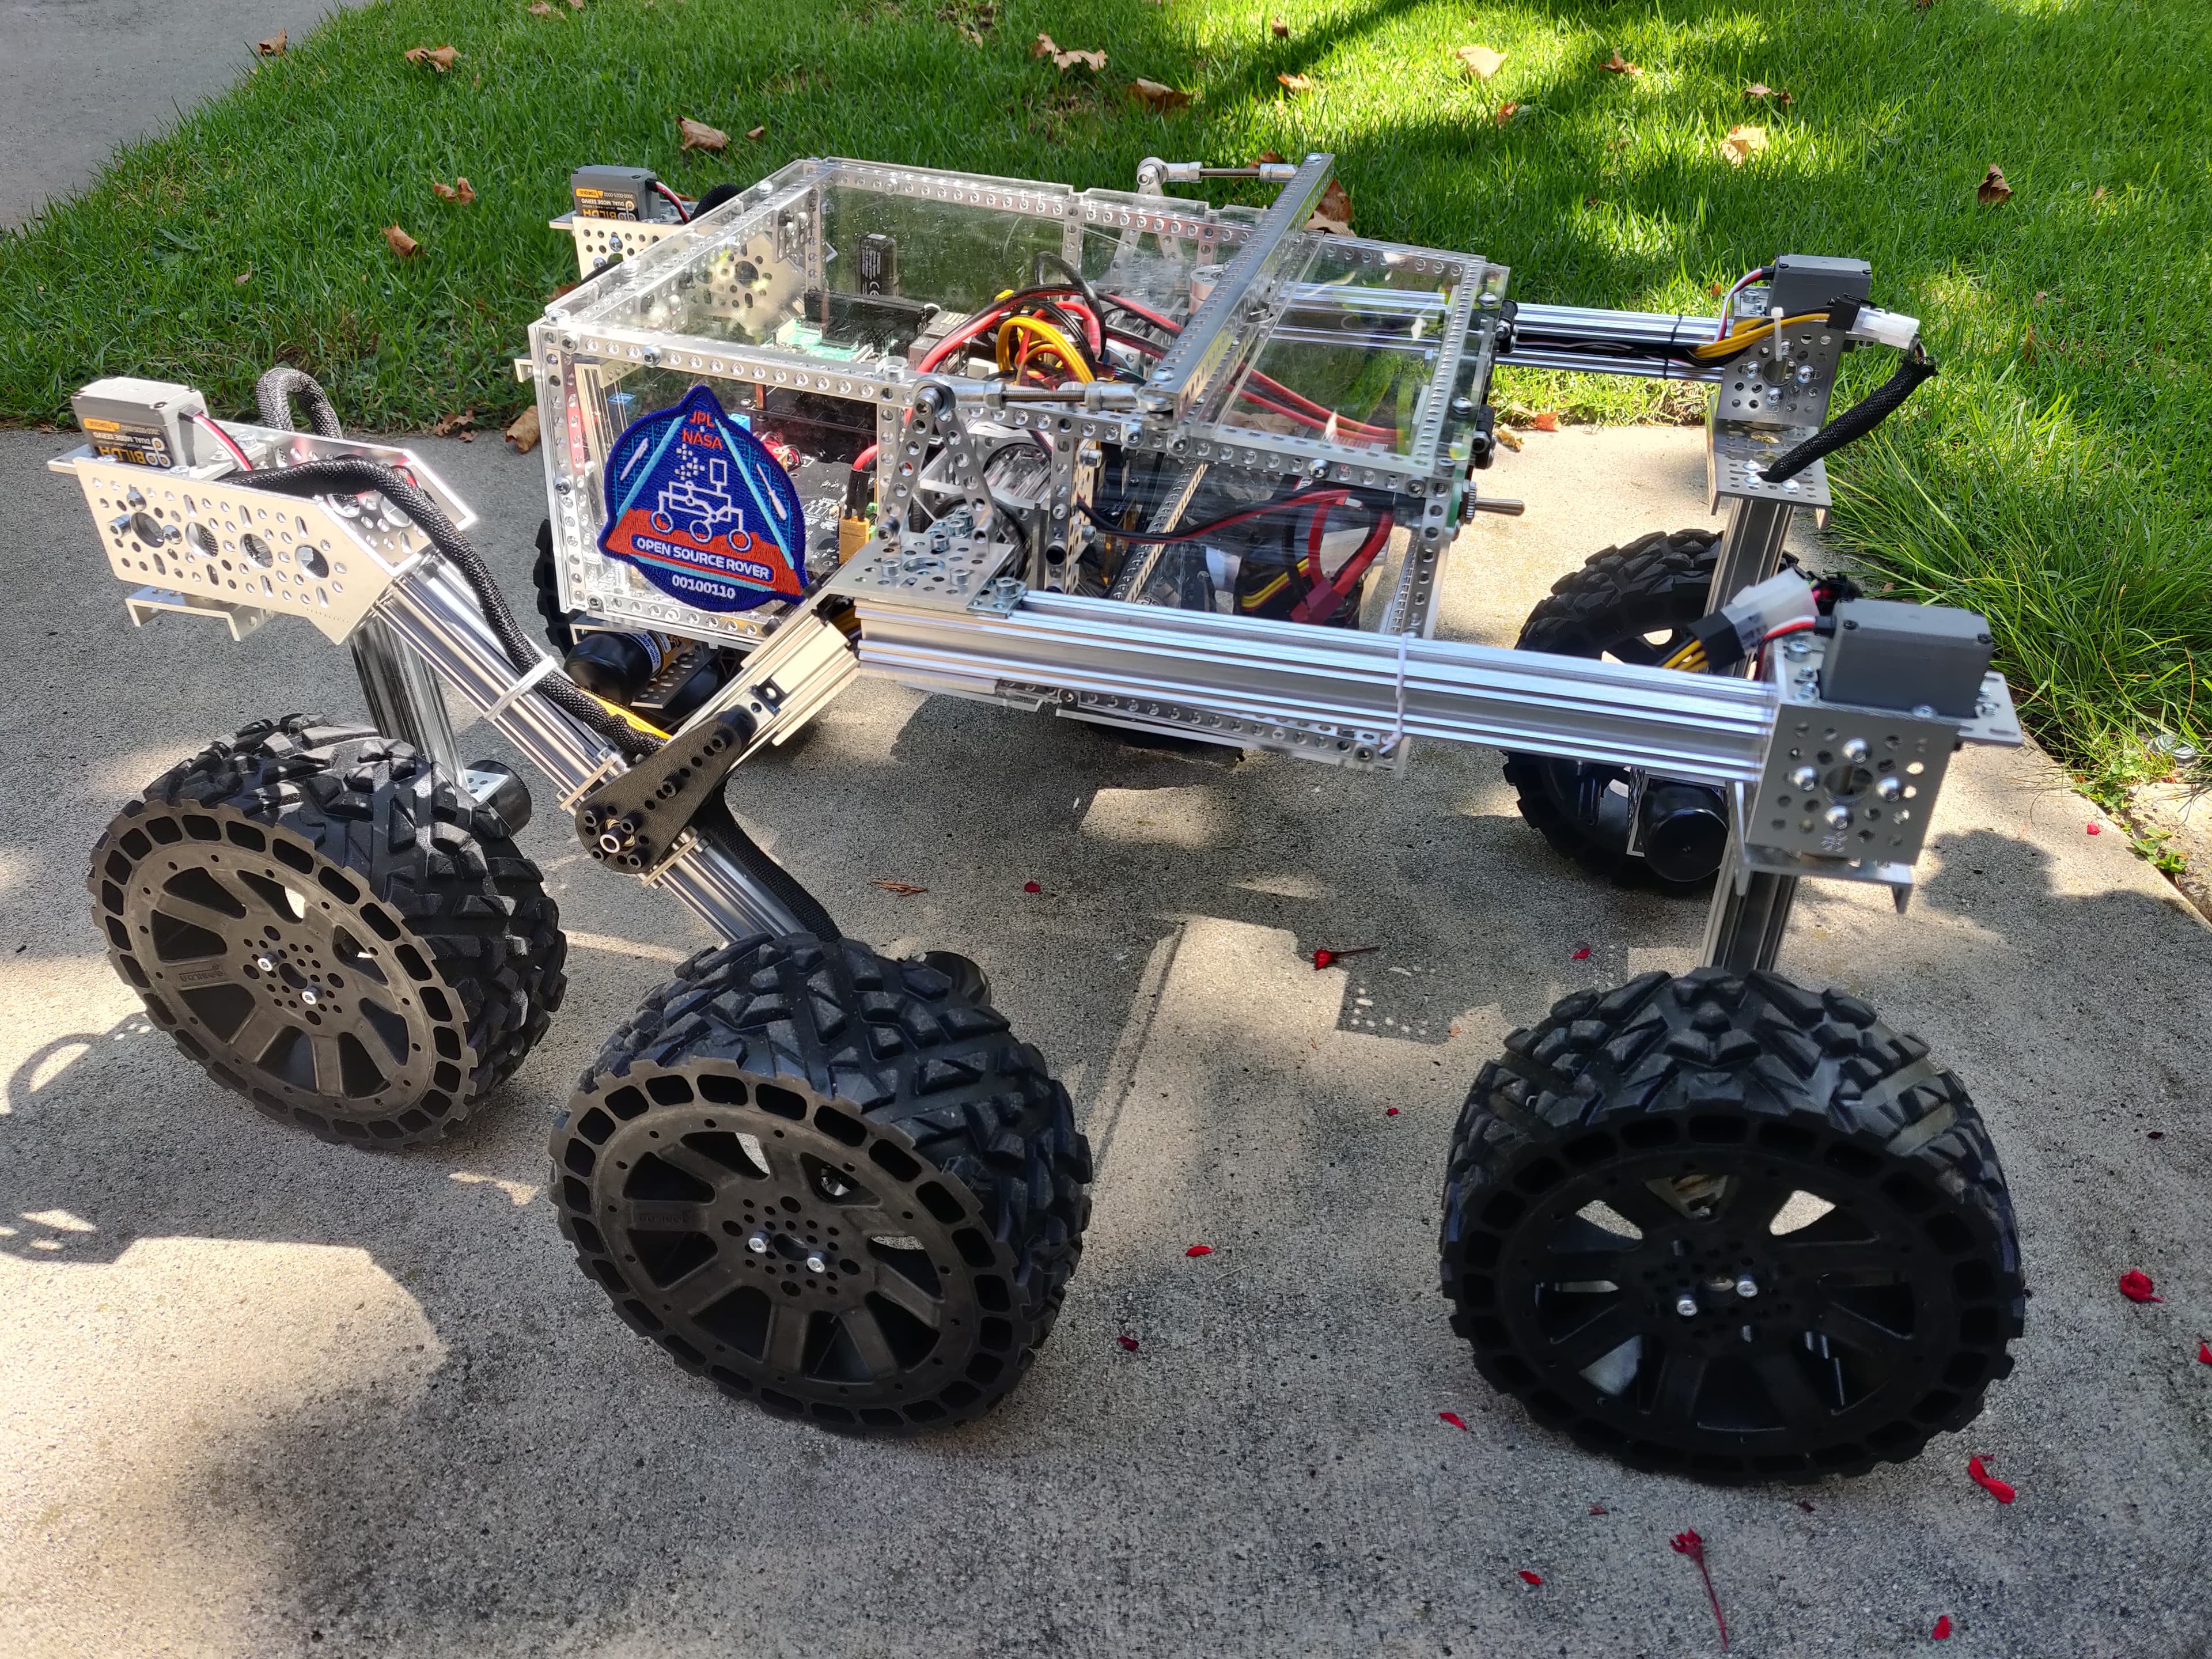
Before you build
Five answers, each linked to its source
What does it cost?
About $1,600full build
About $1,600 for the complete rover, which the README compares to a TurtleBot 3 Waffle. README spec table
Can I sell what I build?
YesCommercial use OK
Hardware Apache-2.0 · Software Apache-2.0. Licensing source
What’s open?
6 of 6CAD: AvailableBOM: AvailablePCB: AvailableCode: AvailableSim: AvailableGuide: Available
All six available. All six files
What does it run on?
Simulation: Gazebo URDF/xacro model in the rover-code repo. Software
Is it maintained?
Active
Latest activity Oct 20, 2026 · main repo last commit Sep 3, 2026 · 22 commits in the last 52 weeks · 52 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
A build-it-yourself, scaled-down version of the six-wheel rover design JPL uses on Mars. It has rocker-bogie suspension, a differential pivot and six-wheel Ackermann steering. It is built from off-the-shelf aluminium parts and runs ROS 2 on a Raspberry Pi.
Hardware
- Actuators
- 10 · motors README
- Build
- Aluminium · off-the-shelf · no machining Documentation
- Drive
- 6 wheels on rocker-bogie suspension with a differential pivot README
- Steering
- Six-wheel Ackermann README
- Top speed
- About 1.6 m/s, depending on the motors README
- Motors
- 10 README
- Battery life
- 3+ hours on rough terrain with a 7.2 Ah battery README
- Computer
- Raspberry Pi running ROS 2 (tested on Foxy) osr-rover-code
Building it
Software & simulation
- Runs on
- ROS 2GazeboRaspberry Pi
- ROS 2
- Rover code runs on ROS 2 (tested on Foxy) with Python 3 osr-rover-code
- Gazebo
- URDF/xacro model for simulation osr-rover-code
- Raspberry Pi
- Anything the Pi can talk to (Bluetooth, Wi-Fi, USB) can drive it README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STEP files and a public Onshape model | Apache-2.0 | Repo files |
| Bill of materials | Available | Complete parts list | Apache-2.0 | parts_list/ |
| Electronics | Available | KiCad PCB with soldering and test instructions | Apache-2.0 | electrical/pcb |
| Code | Available | ROS 2 and Python rover code | Apache-2.0 | osr-rover-code |
| Simulation model | Available | Gazebo URDF/xacro model in the rover-code repo | Apache-2.0 | osr_gazebo |
| Assembly guide | Available | Five-stage build roadmap with wiring, PCB and mechanical guides | Apache-2.0 | README |
03 / Know before you build
Can you sell it?
YesCommercial use OK
Hardware and code are Apache-2.0, and the rover is OSHWA-certified open hardware (US002551). You can build, modify and sell robots based on it, as long as you keep the license and notices.
- Hardware
- Apache-2.0
- Software
- Apache-2.0
04 / The upstream project
Is it maintained?
ActiveLatest activity Oct 20, 2026, 1 day before the snapshot
The main repository’s last commit was Sep 3, 2026.
- Stars
- 9,723
- Forks
- 1,516
- Contributors
- 52
- Latest release
- v4.0.0 · Sep 14, 2023
The companion osr-rover-code repo had a commit on 20 Oct 2026.
Companion repositories
Snapshot captured Oct 21, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
About $1,600
full build
About $1,600 for the complete rover, which the README compares to a TurtleBot 3 Waffle.
README spec tableKit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other rovers.
Closest documented maker’s cost first, then the most recently active rovers. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| JPL Open Source RoverThis robotNASA Jet Propulsion Laboratory | About $1,600full build | 6 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ROS 2GazeboRaspberry Pi | ActiveOct 20, 2026 | 9,723 |
| Autonomous Zero-Turn Retrofit KitZoheb Alvi | About $1,644functional build | 5 of 6 | YesHW MIT · SW not documented | ArduinoESP32Raspberry Pi | Not documented | — |
| Sawppy the RoverRoger-random | $500project budget | 4 of 6 | YesHW MIT · SW MIT | ArduinoROS 1ROS 2 | Not documented | — |
| ArlokSettorezero | Not documented | 4 of 6 | Check firstHW not documented · SW not documented | Arduino | ActiveOct 26, 2026 | 24 |
| This robotJPL Open Source Rover | Autonomous Zero-Turn Retrofit Kit | Sawppy the Rover |
|---|---|---|
| Cost | ||
| About $1,600 | About $1,644 | $500 |
| Can I sell it? | ||
| Yes | Yes | Yes |
| Open files | ||
| 6 of 6 | 5 of 6 | 4 of 6 |
| Runs on | ||
| ROS 2, Gazebo, Raspberry Pi | Arduino, ESP32, Raspberry Pi, Python | Arduino, ROS 1, ROS 2, Raspberry Pi |
| Maintained | ||
| ActiveOct 20, 2026 | Not documented | Not documented |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the tableConnected projects and guides
Keep exploring.
- PREVIOUS VERSIONOSR v3.1.0 Previous major version, still tagged in the repo
- ALTERNATIVESawppy Cheaper Mars-rover replica listed by JPL
- ALTERNATIVEESA ExoMy Rover replica listed by JPL
- COMPANIONosr-rover-code ROS 2 software for the rover
- VIDEOOSR2 in action YouTube
- CERTIFICATEOSHWA certification US002551 Open Source Hardware Association
07 / Follow the evidence
Open books.
Repository files are pinned to commit 0bea824. Websites and papers are listed with their review dates.
- 01README at commit 0bea824Reviewed Oct 21, 2026
- 02LICENSE.txt (Apache-2.0)Reviewed Oct 21, 2026
- 03OSHWA certificate US002551Reviewed Oct 21, 2026
- 04osr-rover-code README (ROS 2)Reviewed Oct 21, 2026
- 05GitHub API: stars, contributors, commit activityReviewed Oct 21, 2026