ToddlerBot
A 0.56 m research humanoid with 30 actuated joints, a MuJoCo digital twin and teleoperation for demonstrations.
Project documentation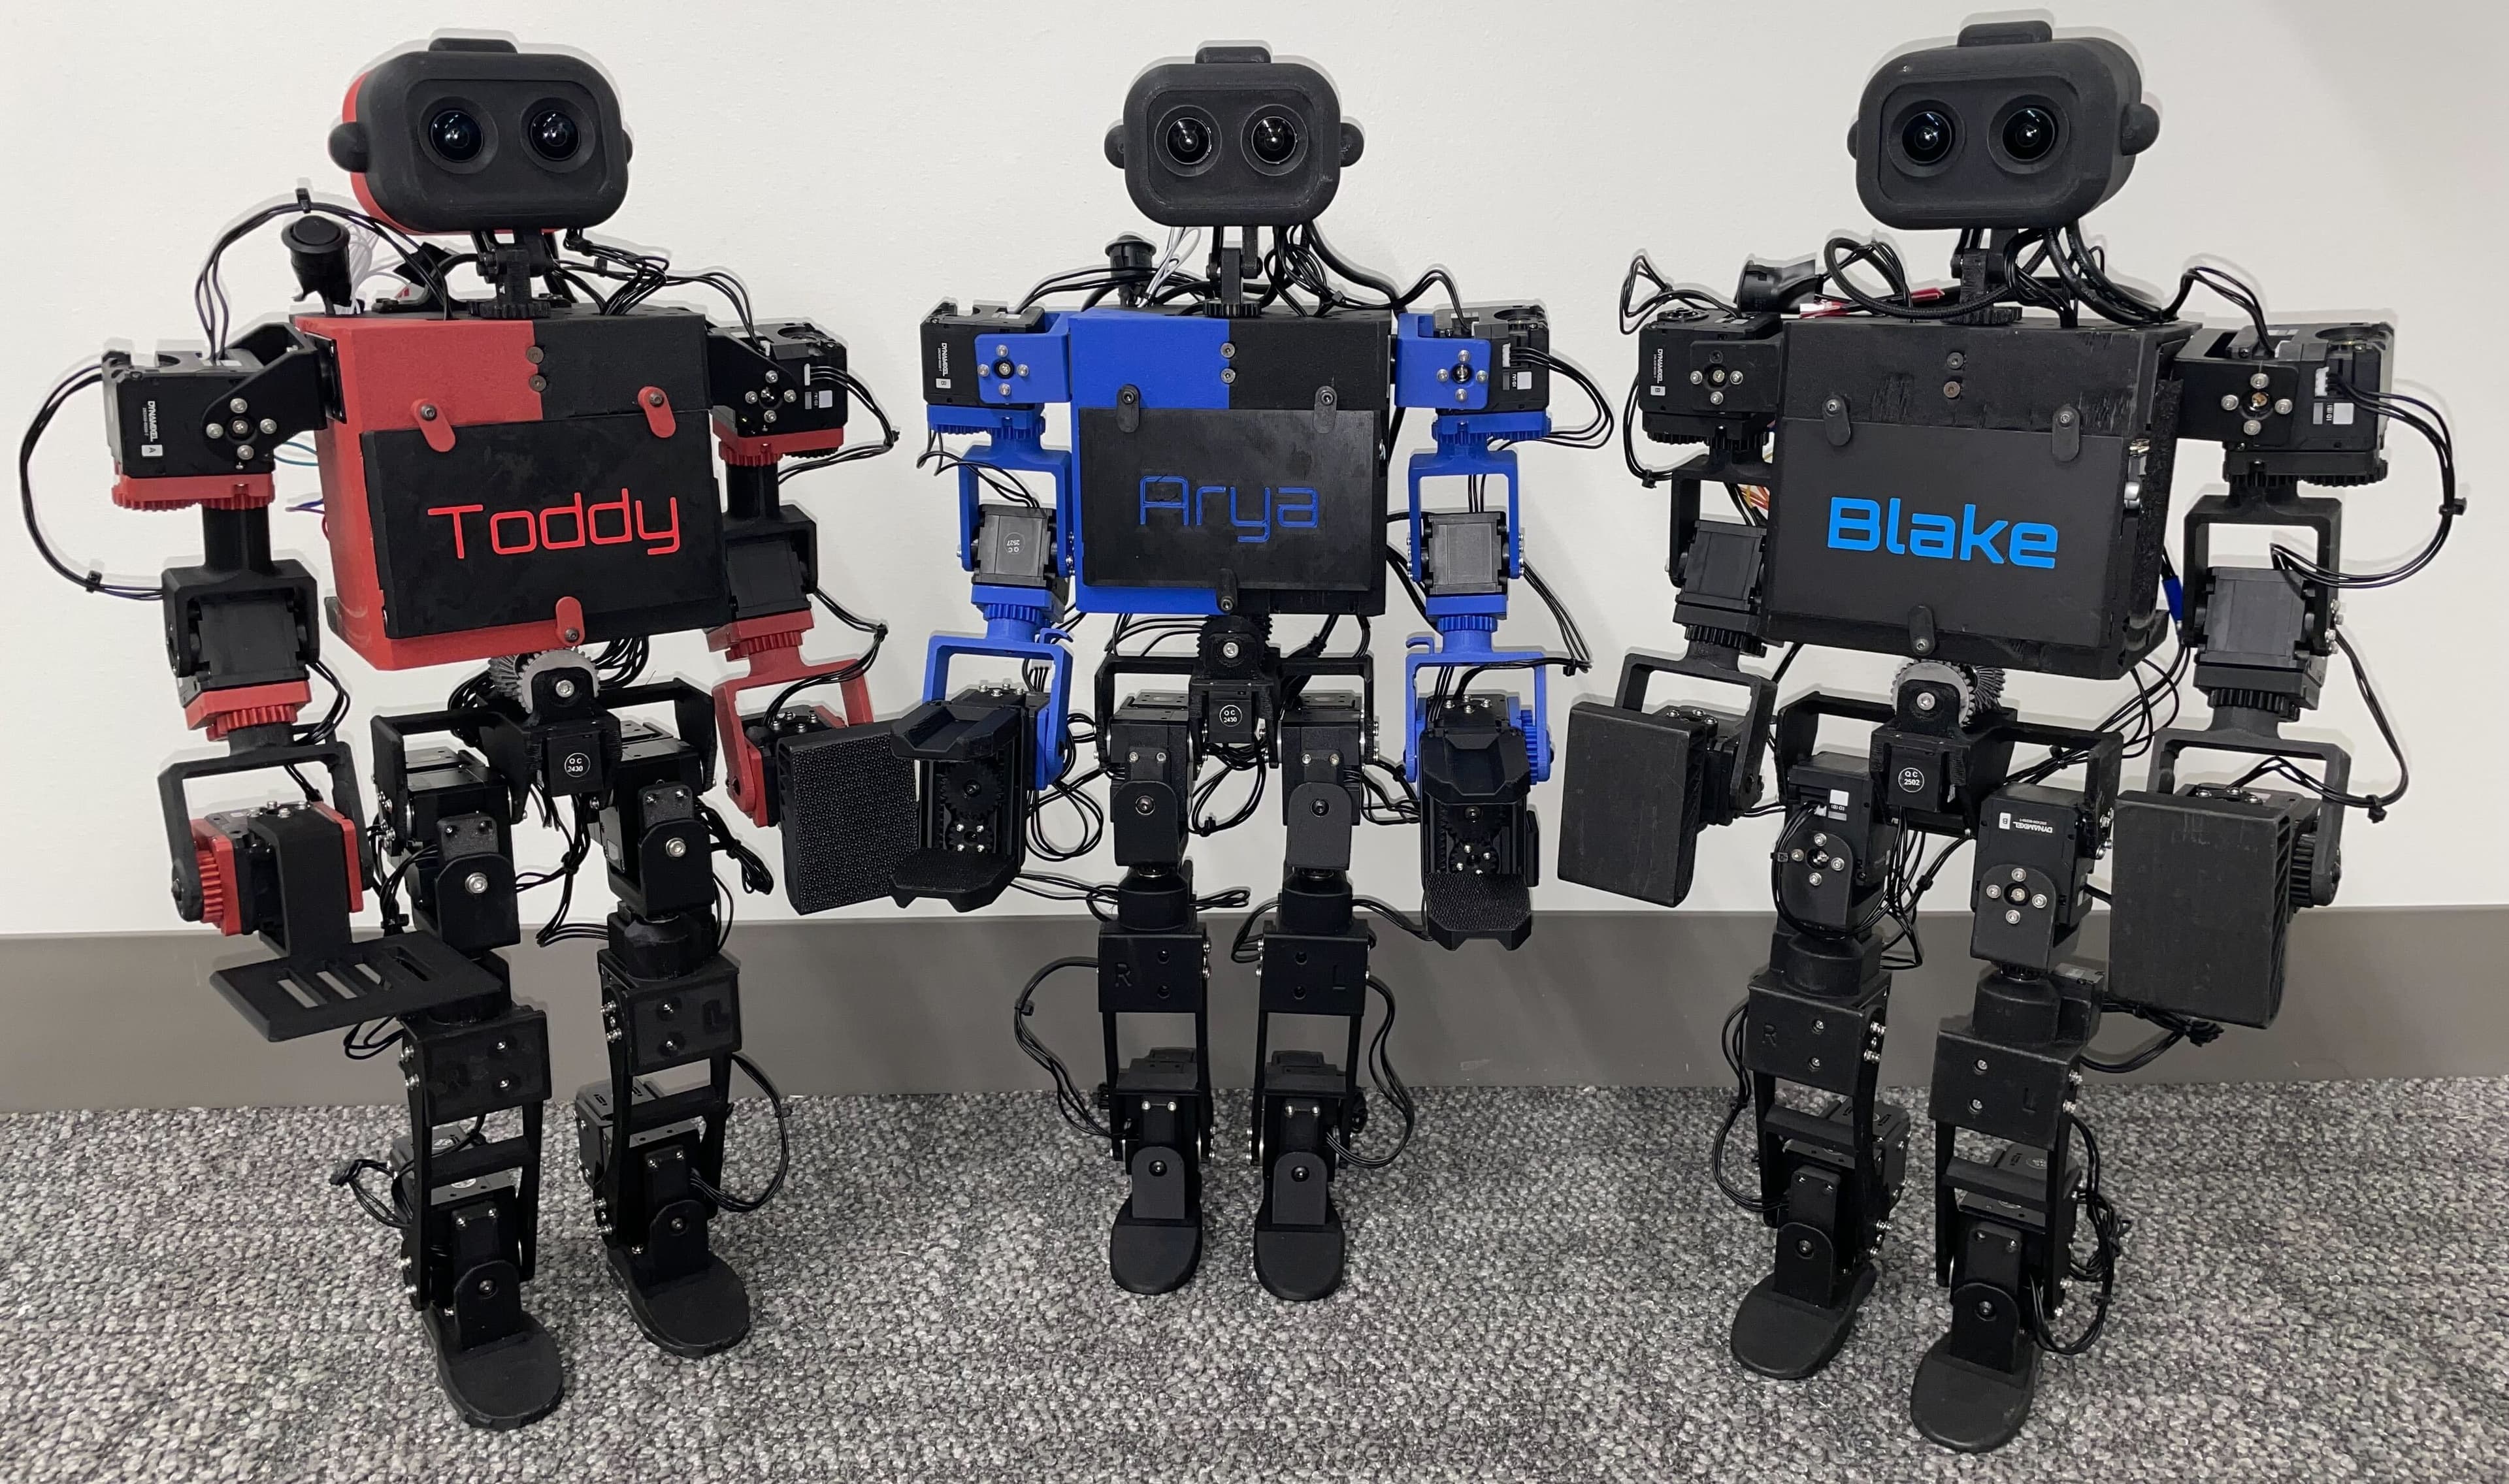
Before you build
Five answers, each linked to its source
What does it cost?
Under $6,000whole robot
The authors put the total cost of one robot under 6,000 USD. ToddlerBot paper abstract
Can I sell what I build?
NoNon-commercial hardware
Hardware CC BY-NC-SA 4.0 · Software MIT. Licensing source
What’s open?
5 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: AvailableGuide: Available
PCB not documented. All six files
What does it run on?
Is it maintained?
Quiet
Latest activity Apr 19, 2026 · 3 commits in the last 52 weeks · 8 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
A 0.56 m, 3.4 kg humanoid built for robot-learning research. It is entirely 3D-printed around commercially available components, has 30 actuated joints and pairs the real robot with a MuJoCo digital twin and a teleoperation interface for collecting demonstrations. An independent team has rebuilt it from the documentation.
Hardware
- Actuators
- 30 · active DoF Project site
- Build
- 3D-printed · entire structure Documentation
- Height · weight
- 0.56 m · 3.4 kg Paper
- Actuated joints
- 30: 7 per arm, 6 per leg, 2 in the neck, 2 in the waist Project site
- Hands
- Two end-effector designs: a gripper or a palm Project site
- Construction
- Entirely 3D-printed, with commercially available components Paper
- Calibration
- Plug-and-play zero-point calibration and transferable motor system identification Paper
- Reproducibility
- Independently replicated from the documentation Paper
Building it
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | Public Onshape document, plus STL files on MakerWorld | CC BY-NC-SA 4.0 | README |
| Bill of materials | Available | CSV BOM in the docs folder | MIT (docs) | bom.csv |
| Electronics | Not documented | Not established from the sources we read | Not documented | No source found |
| Code | Available | Control, RL and diffusion-policy training, real-world deployment | MIT | README |
| Simulation model | Available | MuJoCo robot and scene models for the gripper and palm variants | MIT | descriptions/ |
| Assembly guide | Available | Assembly manual (PDF) and assembly videos | MIT (docs) | Manual PDF |
03 / Know before you build
Can you sell it?
NoNon-commercial hardware
The design files (Onshape, STL) are CC BY-NC-SA 4.0. You can build and modify ToddlerBot for non-commercial use and must share changes under the same license. Selling robots or parts made from the design needs the authors’ permission. The code is MIT.
- Hardware
- CC BY-NC-SA 4.0
- Software
- MIT
04 / The upstream project
Is it maintained?
QuietLatest activity Apr 19, 2026, 185 days before the snapshot
- Stars
- 785
- Forks
- 94
- Contributors
- 8
- Latest release
- None recorded
Snapshot captured Oct 21, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Under $6,000
whole robot
The authors put the total cost of one robot under 6,000 USD.
ToddlerBot paper abstractKit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other humanoids.
The three humanoids with the closest documented maker’s cost. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| ToddlerBotThis robotHaochen Shi, C. Karen Liu et al. · Stanford | Under $6,000whole robot | 5 of 6 | NoHW CC BY-NC-SA 4.0 · SW MIT | MuJoCoPython | QuietApr 19, 2026 | 785 |
| Poppy Torsopoppy-project | €5,300complete kit | 4 of 6 | Yes, with creditHW Creative Commons BY-SA · SW GPL v3 | Python | DormantMar 24, 2022 | 51 |
| MicrobanMarc Duclusaud | About $567Microban robot | 5 of 6 | NoHW CC BY-NC-SA 4.0 · SW GNU GPL v3 | Raspberry Pi | ActiveOct 30, 2026 | 645 |
| Asimov 1menloresearch | $20,000DIY Kit | 3 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW GPL-2.0 | MuJoCoRaspberry Pi | ActiveOct 30, 2026 | 1,373 |
| This robotToddlerBot | Poppy Torso | Microban |
|---|---|---|
| Cost | ||
| Under $6,000 | €5,300 | About $567 |
| Can I sell it? | ||
| No | Yes, with credit | No |
| Open files | ||
| 5 of 6 | 4 of 6 | 5 of 6 |
| Runs on | ||
| MuJoCo, Python | Python | Raspberry Pi |
| Maintained | ||
| QuietApr 19, 2026 | DormantMar 24, 2022 | ActiveOct 30, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the tableConnected projects and guides
Keep exploring.
- UPDATEToddlerBot 2.0 Released August 2025, with a changelog and migration guide in the repo
- RESEARCHLocomotion Beyond Feet 2026 multi-skill whole-body locomotion system on ToddlerBot
- LAUNCH POSTAnnouncement on X · 3 Feb 2025 @HaochenShi74
- VIDEOToddlerBot release video YouTube
- PAPERToddlerBot · arXiv 2502.00893 Open-source ML-compatible humanoid platform
- PAPERLocomotion Beyond Feet · arXiv 2601.03607 2026 follow-up
07 / Follow the evidence
Open books.
Repository files are pinned to commit e337f3b. Websites and papers are listed with their review dates.
- 01README at commit e337f3b (license section)Reviewed Oct 21, 2026
- 02ToddlerBot paper abstract, arXiv 2502.00893Reviewed Oct 21, 2026
- 03Project website (DoF breakdown)Reviewed Oct 21, 2026
- 04docs/_static/bom.csvReviewed Oct 21, 2026
- 05GitHub API: stars, contributors, commit activityReviewed Oct 21, 2026