Yertle
A 3D-printed quadruped for locomotion research, with four hobby-servo-powered limbs and printable parts.
Project documentation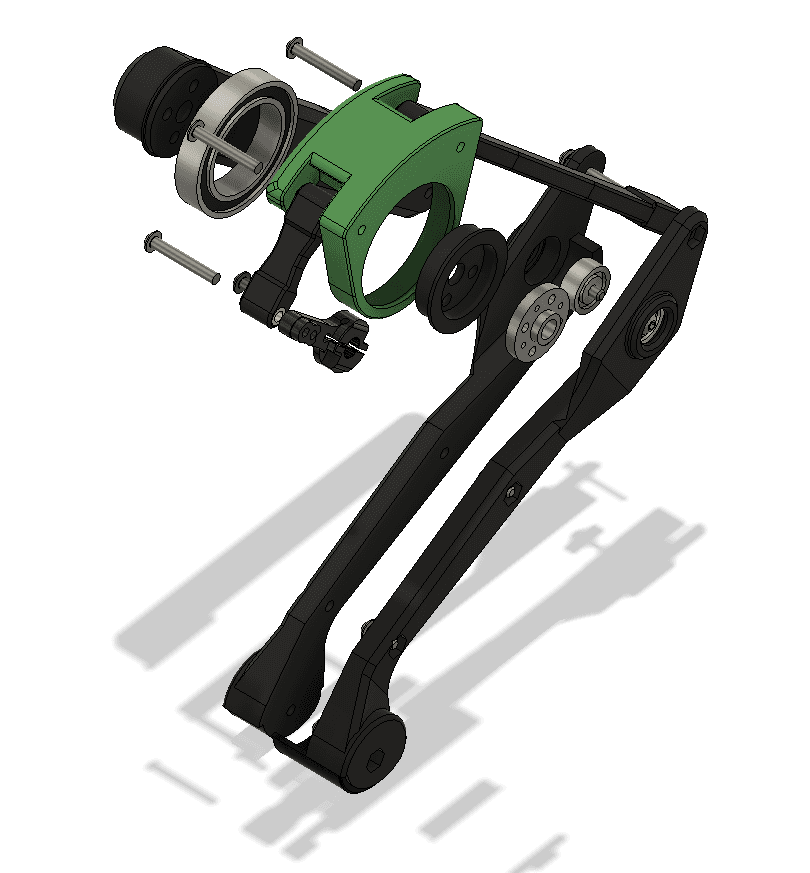
Before you build
Five answers, each linked to its source
What does it cost?
About £250robot
The README gives the current cost of the robot as around £250. README
Can I sell what I build?
YesCommercial use OK
Hardware MIT · Software MIT. Licensing source
What’s open?
5 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: AvailableGuide: Available
PCB not documented. All six files
Is it maintained?
Active
Latest activity Sep 16, 2026 · main repo last commit Sep 16, 2026 · 19 commits in the last 52 weeks · 2 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
Yertle is a 3D-printed quadruped for locomotion research. Its four limbs each have 3 degrees of freedom and are powered by hobby servos; the stated leg extension is approximately 20 cm. The repository links to 3D printer parts, assembly instructions and a bill of materials.
Hardware
- Actuators
- Not documented Documentation
- Build
- 3D-printed · 3D printer parts Documentation
- Limbs
- 4 limbs, each with 3 degrees of freedom README
- Leg extension
- Approximately 20 cm README
- Weight
- 1.8 kg README
Building it
- Build resources
- The design README links to 3D printer parts, assembly instructions and a bill of materials. README
Software & simulation
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | CAD and printable robot parts are provided. | Not documented | CAD/ |
| Bill of materials | Available | The design README links to a bill of materials. | Not documented | README.md |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | Robot firmware and host control software are described. | Not documented | software/ |
| Simulation model | Available | URDF model. | Not documented | yertle.urdf |
| Assembly guide | Available | Assembly instructions are linked from the design README. | Not documented | README.md |
03 / Know before you build
Can you sell it?
YesCommercial use OK
The whole repository, design files included, is MIT. You can build, modify and sell robots based on it, as long as you keep the license and copyright notices.
- Hardware
- MIT
- Software
- MIT
04 / The upstream project
Is it maintained?
ActiveLatest activity Sep 16, 2026, 44 days before the snapshot
The main repository’s last commit was Sep 16, 2026.
- Stars
- 168
- Forks
- 24
- Contributors
- 2
- Latest release
- v1.0.0 · Aug 27, 2026
Snapshot captured Oct 30, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other quadrupeds.
Closest documented maker’s cost first, then the most recently active quadrupeds. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| YertleThis robotJerome-Graves | About £250robot | 5 of 6 | YesHW MIT · SW MIT | ROS 2PyBulletIsaac | ActiveSep 16, 2026 | 168 |
| Physical AntOpenmind-Research-Institute | $2,230.61BOM total | 4 of 6 | YesHW MIT · SW MIT | PythonMuJoCo | ActiveOct 29, 2026 | 76 |
| Spot Micro - LeikaRune Harlyk | Not documented | 4 of 6 | YesHW MIT · SW MIT License | ESP32MuJoCo | ActiveOct 29, 2026 | 92 |
| SesameDorian Todd | Not documented | 6 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ESP32ArduinoPython | ActiveOct 15, 2026 | 4,876 |
| This robotYertle | Physical Ant | Spot Micro - Leika |
|---|---|---|
| Cost | ||
| About £250 | $2,230.61 | Not documented |
| Can I sell it? | ||
| Yes | Yes | Yes |
| Open files | ||
| 5 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| ROS 2, PyBullet, Isaac, Python, Arduino | Python, MuJoCo | ESP32, MuJoCo |
| Maintained | ||
| ActiveSep 16, 2026 | ActiveOct 29, 2026 | ActiveOct 29, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit 9d04e2d. Websites and papers are listed with their review dates.
- 01README.md at 9d04e2dReviewed Oct 30, 2026
- 02LICENSE at 9d04e2dReviewed Oct 30, 2026