ALTO 3D Printed 6 Axis Robotic Arm (WIP)
A 3D-printed robotic arm using harmonic-drive reducers and NEMA stepper motors, controlled over USB with a Python API.
Project documentation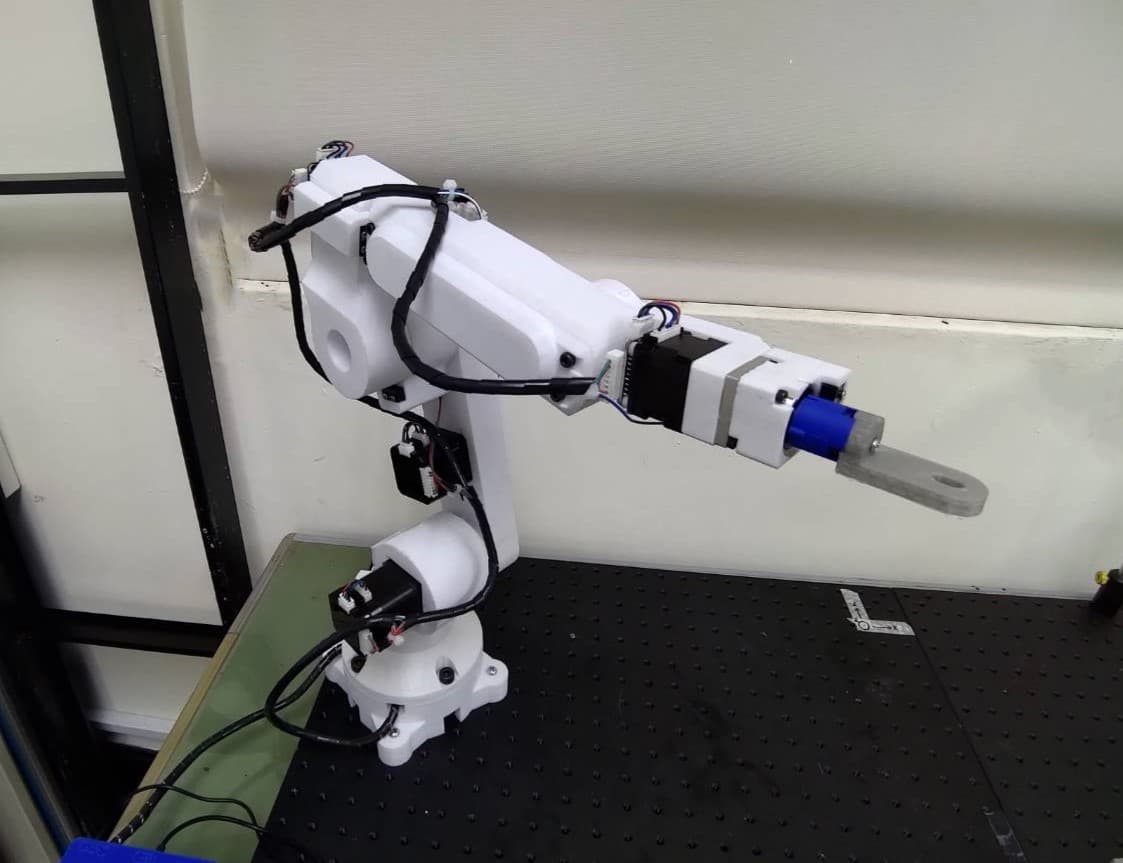
Before you build
Five answers, each linked to its source
What does it cost?
About $400total for the robot
The maker reports spending around 400 USD in total on the robot. README
Can I sell what I build?
YesCommercial use OK
Hardware MIT · Software MIT. Licensing source
What’s open?
3 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: Not documentedGuide: Not documented
PCB, sim, guide not documented. All six files
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
ALTO is a 3D-printed robotic arm that uses harmonic-drive reducers and NEMA17 and NEMA14 stepper motors. Its control box connects to a computer over USB, and a Python API is provided to operate the robot. The repository includes hardware CAD files and a bill of materials.
Hardware
- Actuators
- Not documented Documentation
- Build
- 3D-printed · PLA+ Documentation
- Axes
- 6 README
Building it
- Filament
- PLA+ README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | Fusion 360 and STEP files are listed in the hardware directory. | Not documented | alto_t_3 v108.f3z |
| Bill of materials | Available | The README identifies a bill of materials in the hardware folder. | Not documented | alto_bom.xlsx |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | Firmware source code is in the firmware folder. | Not documented | firmware/ |
| Simulation model | Not documented | Not documented | Not documented | No source found |
| Assembly guide | Not documented | Not documented | Not documented | No source found |
03 / Know before you build
Can you sell it?
YesCommercial use OK
The whole repository, design files included, is MIT. You can build, modify and sell robots based on it, as long as you keep the license and copyright notices.
- Hardware
- MIT
- Software
- MIT
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
About $400
total for the robot
The maker reports spending around 400 USD in total on the robot.
READMEKit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other arms.
The three arms with the closest documented maker’s cost. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| ALTO 3D Printed 6 Axis Robotic Arm (WIP)This robotliaochikon | About $400total for the robot | 3 of 6 | YesHW MIT · SW MIT | Python | Not documented | — |
| Ark_BotRobotics-Ark | £348.12Amazon total | 4 of 6 | YesHW MIT · SW MIT | Python | DormantOct 13, 2025 | 32 |
| PingTi Armnomorewzx | About $261single PingTi arm | 4 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | LeRobot | ActiveOct 20, 2026 | 55 |
| AM-ARM200Li Yiteng and Wu Zhiyong | $243.33follower arm BOM | 4 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | LeRobot | QuietJun 18, 2026 | 90 |
| This robotALTO 3D Printed 6 Axis Robotic Arm (WIP) | Ark_Bot | PingTi Arm |
|---|---|---|
| Cost | ||
| About $400 | £348.12 | About $261 |
| Can I sell it? | ||
| Yes | Yes | Yes |
| Open files | ||
| 3 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| Python | Python | LeRobot |
| Maintained | ||
| Not documented | DormantOct 13, 2025 | ActiveOct 20, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit f83587b. Websites and papers are listed with their review dates.
- 01README.md at f83587bReviewed Oct 31, 2026
- 02LICENSE at f83587bReviewed Oct 31, 2026