Antagonistic Tendon Driven Continuum Robot
A research continuum robot with four degrees of freedom, driven by tendons and equipped for tendon-force measurement.
Project documentation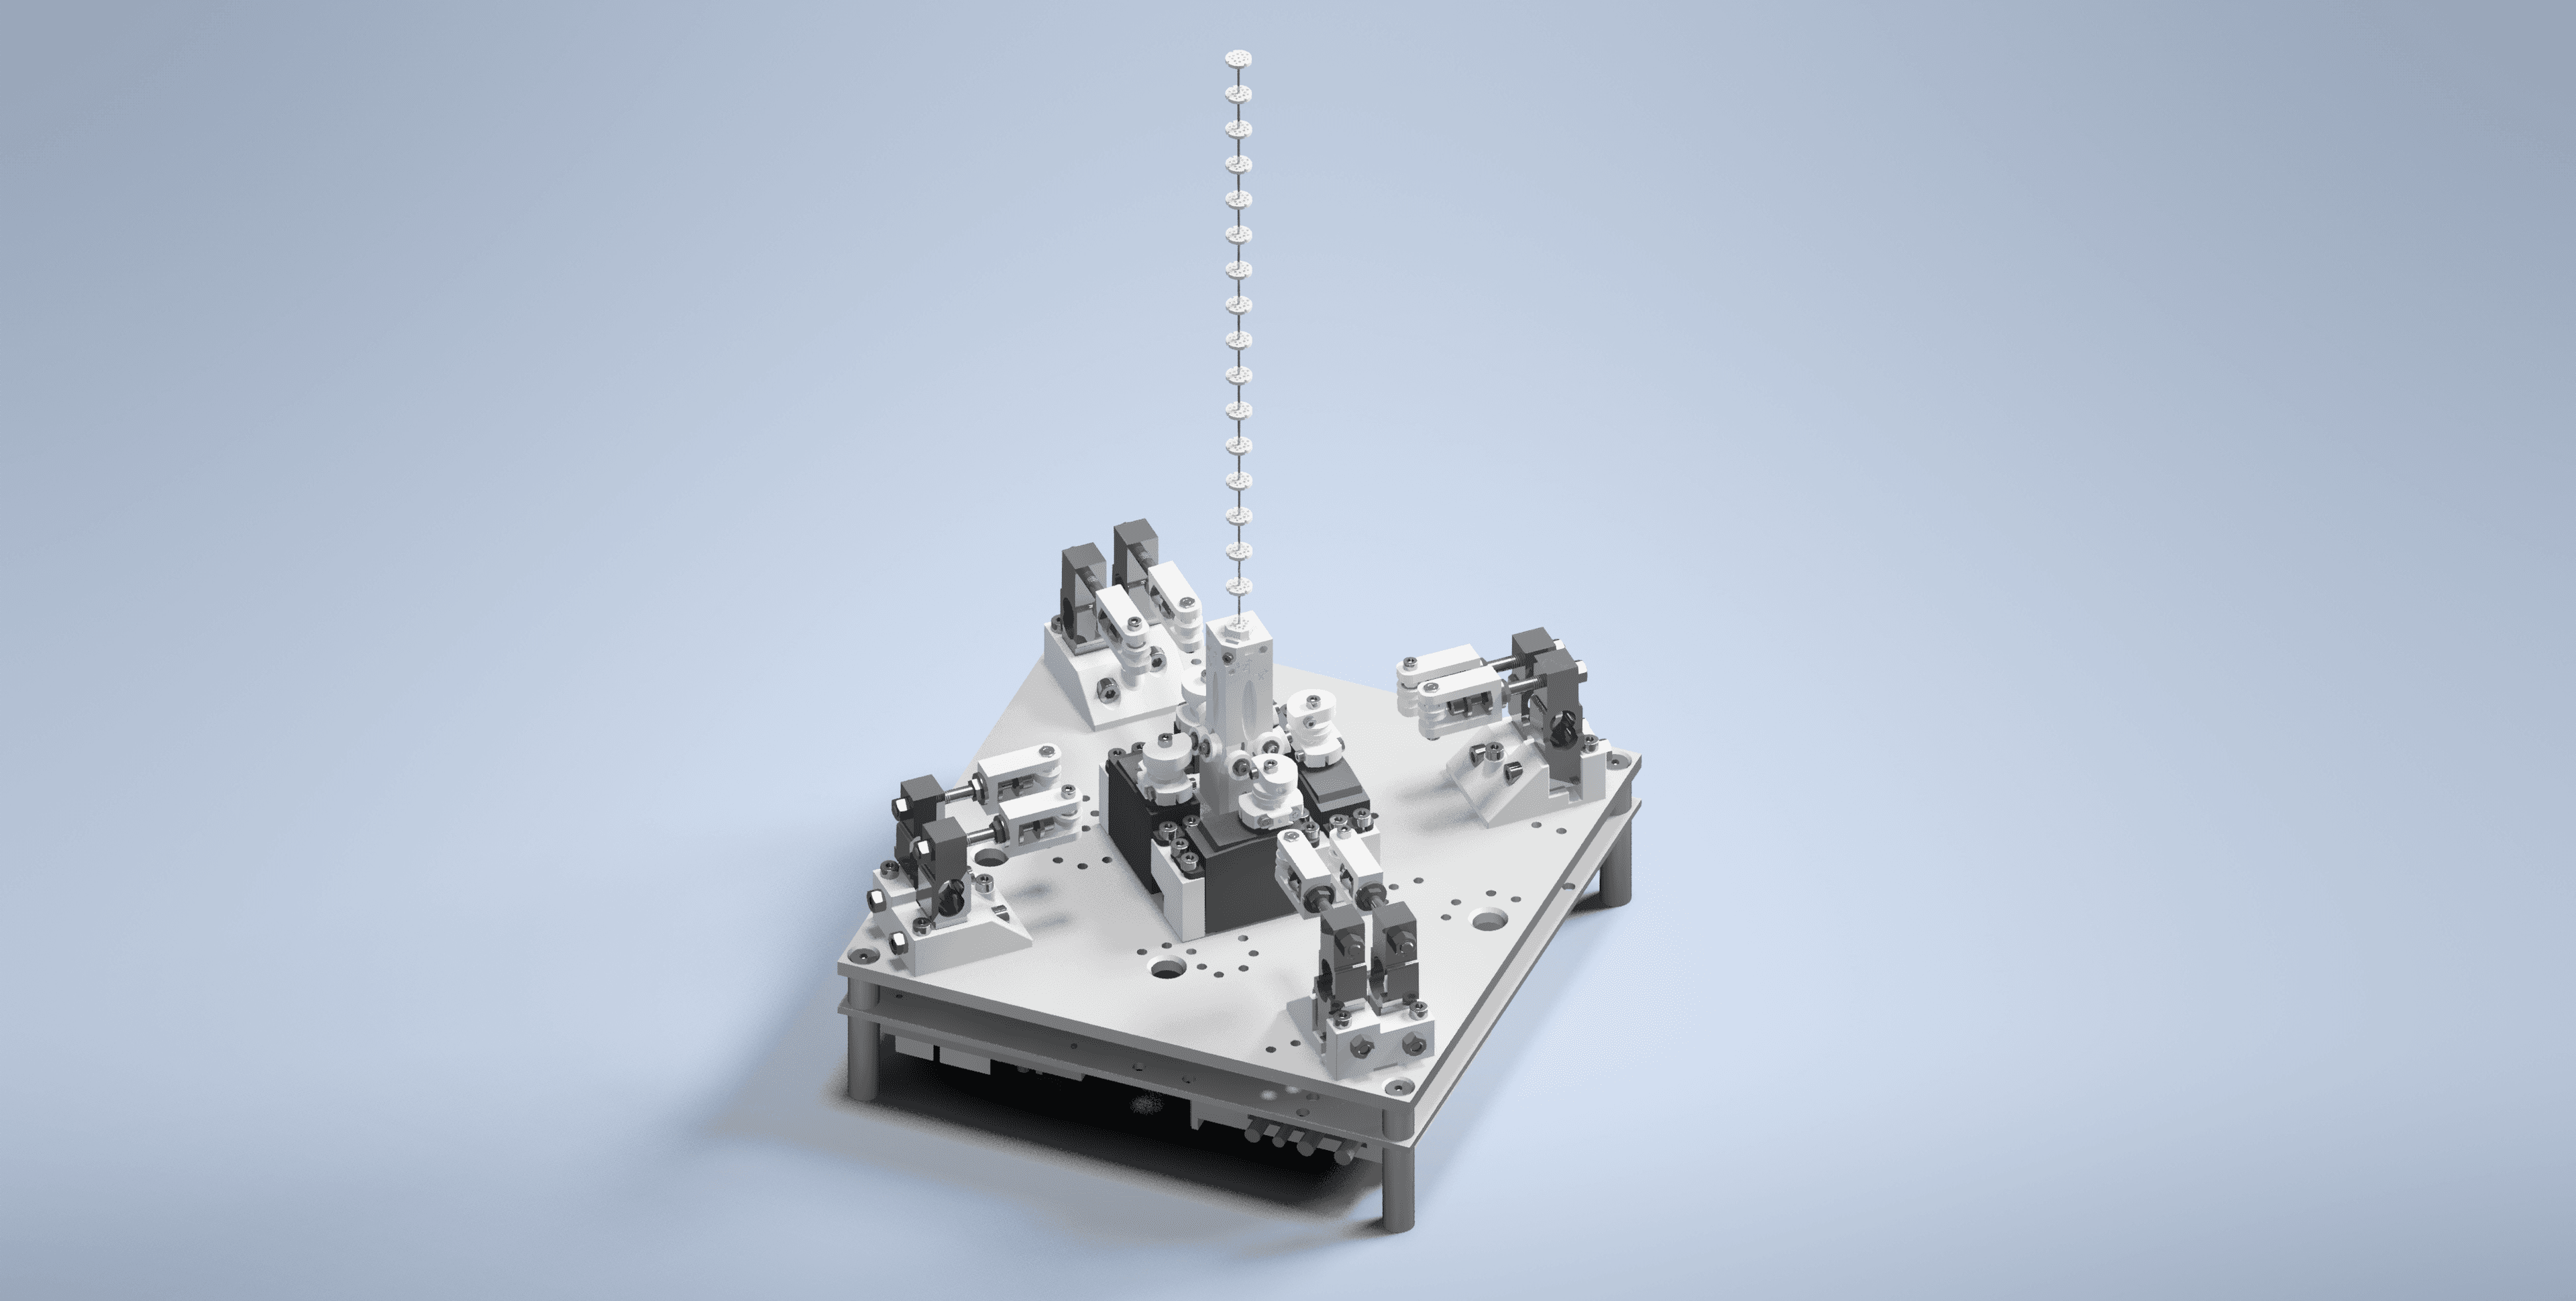
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Yes, with creditCommercial use OK, with credit
Hardware CERN-OHL-W-2.0 · Software CERN-OHL-W-2.0. Licensing source
What’s open?
1 of 6CAD: AvailableBOM: PartialPCB: Off-the-shelf partCode: PartialSim: Not documentedGuide: Partial
BOM, code, guide partial · sim not documented · PCB off-the-shelf. All six files
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
The robot drives two tendons with a single servo, routing them via load cells for tendon-force measurement. Its design is divided into substructure, base, force-measurement, and robot-body modules; the repository provides STEP files and basic ROS interfacing information.
Hardware
- Actuators
- Not documented Documentation
- Build
- Mixed · SLS-designed printed parts and off-the-shelf components Documentation
- Degrees of freedom
- 4 README
- Tendons
- 2 README
- Force measurement
- Tendon force measurement via load cells README
Building it
- 3D printing
- All 3D-printed parts are designed for SLS printing. README
- Assembly information
- Modules_and_BOM.pdf provides some information on assembly and required materials. README
- Off-the-shelf parts
- Listed parts include servo motors, load cells, tendons, bearings, an Arduino Uno, bolts and nuts. README
Software & simulation
- Runs on
- Arduino
- ROS interfacing
- Basic interfacing software and information for ROS are provided. README
- Servo control
- Arduino firmware uses rosserial to provide topics to the ROS network and sets motor position when a new message arrives. README
- Load-cell data
- A suitable ROS package for the Phidget 4-Input Bridges publishes values to individual topics. README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STEP files are provided, including a full-robot STEP file. | Not documented | full_robot.stp |
| Bill of materials | Partial | PDF provides some information on assembly and required materials. | Not documented | Modules_and_BOM.pdf |
| Electronics | Off-the-shelf part | An off-the-shelf Arduino Uno is listed among the parts. | — | README |
| Code | Partial | Arduino servo-control firmware is provided. | Not documented | motor_driver.ino |
| Simulation model | Not documented | Not documented | Not documented | No source found |
| Assembly guide | Partial | PDF provides some information on assembly. | Not documented | Modules_and_BOM.pdf |
03 / Know before you build
Can you sell it?
Yes, with creditCommercial use OK, with credit
The whole repository, design files included, is CERN-OHL-W-2.0. Commercial use is allowed if you keep the maker’s copyright and license notices. Changes you distribute to the licensed files must stay under the same license; other parts combined with them may use other terms.
- Hardware
- CERN-OHL-W-2.0
- Software
- CERN-OHL-W-2.0
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other other robots.
Other other robots in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| Antagonistic Tendon Driven Continuum RobotThis robotChristian Marzi | Not documented | 1 of 6 | Yes, with creditHW CERN-OHL-W-2.0 · SW CERN-OHL-W-2.0 | Arduino | Not documented | — |
| openBrushographDominik Mahnic | Not documented | 1 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW not documented | ESP32Arduino | ActiveOct 15, 2026 | 28 |
| Aria Art Plottergustavomayoral | Not documented | 4 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW GPL-3.0 | ArduinoPython | Not documented | — |
| HsiwuRobusr | Not documented | 4 of 6 | YesHW MIT License · SW not documented | Not documented | Not documented | — |
| This robotAntagonistic Tendon Driven Continuum Robot | openBrushograph | Aria Art Plotter |
|---|---|---|
| Cost | ||
| Not documented | Not documented | Not documented |
| Can I sell it? | ||
| Yes, with credit | Yes, with credit | Yes, with credit |
| Open files | ||
| 1 of 6 | 1 of 6 | 4 of 6 |
| Runs on | ||
| Arduino | ESP32, Arduino | Arduino, Python |
| Maintained | ||
| Not documented | ActiveOct 15, 2026 | Not documented |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit b399713. Websites and papers are listed with their review dates.
- 01README.md at b399713Reviewed Nov 1, 2026
- 02LICENSE at b399713Reviewed Nov 1, 2026