Bebo Jr
A small desktop half-humanoid with printable parts, built for human–robot interaction and motion-retargeting work.
Project documentation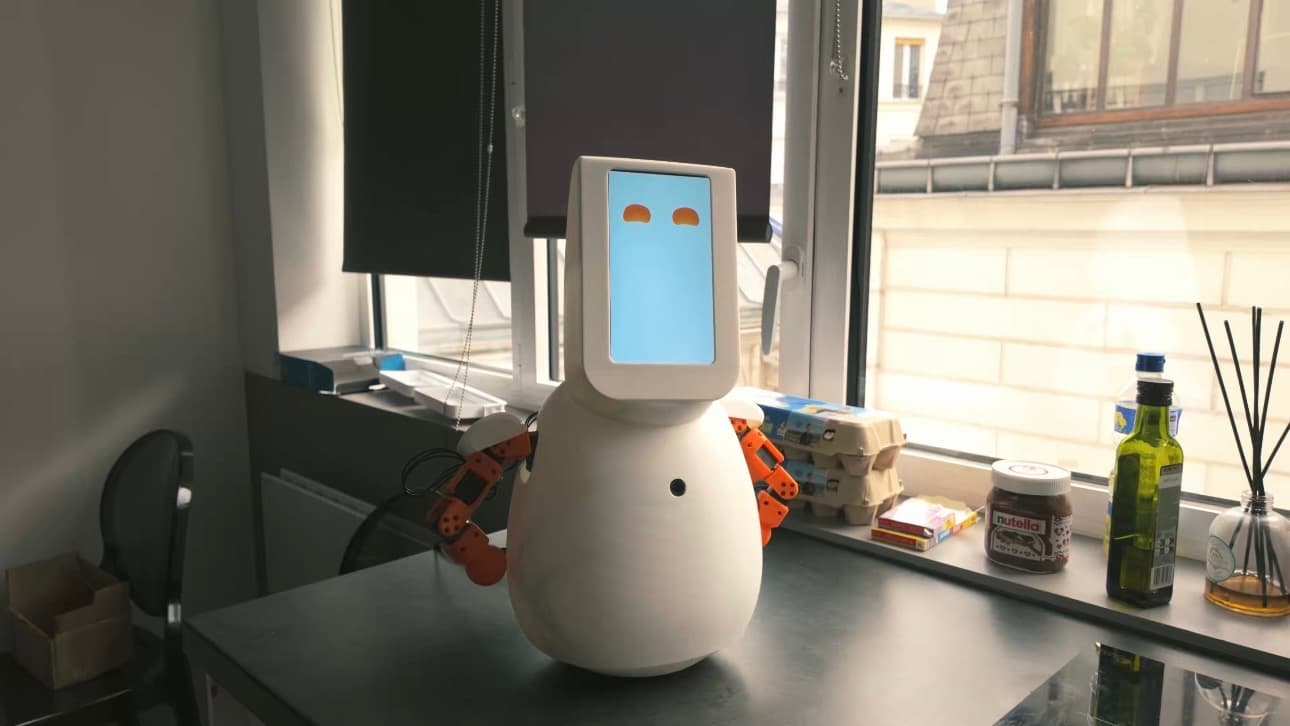
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Yes, with creditCommercial use OK, with credit
Hardware GPL-3.0 · Software GPL-3.0-or-later. Licensing source
What’s open?
4 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: AvailableGuide: Partial
Guide partial · PCB not documented. All six files
What does it run on?
Simulation: Simulation files include URDF and Mujoco formats. Software
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
Bebo Jr is a small desktop half-humanoid intended for human–robot interaction and motion-retargeting work. The repository includes `.3mf` print files, simulation files, and camera-based teleoperation scripts. The README gives PLA print settings and instructions for motor zeroing and IDs.
Hardware
- Actuators
- 10 · XL330-M288T servos README
- Build
- 3D-printed · PLA Documentation
- Servos
- 10 XL330-M288T servos README
- Display
- 7-inch HDMI display README
- Computer
- Raspberry Pi 5 (4GB) README
Building it
Software & simulation
- Runs on
- Raspberry PiMuJoCo
- Motion retargeting
- Camera-based body tracking drives both arms via inverse kinematics in the full retargeting script. README
- Dependency management
- The repository uses uv for dependency management. README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | Public OnShape model linked in the README. | Not documented | cad.onshape.com |
| Bill of materials | Available | README Bill of Materials table lists items and quantities. | Not documented | README.md |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | Motion-retargeting scripts are provided in teleop. | Not documented | teleop/ |
| Simulation model | Available | Simulation files include URDF and Mujoco formats. | Not documented | simulation/ |
| Assembly guide | Partial | README includes print settings and motor zero-position and ID instructions. | Not documented | README.md |
03 / Know before you build
Can you sell it?
Yes, with creditCommercial use OK, with credit
The whole repository, design files included, is GPL-3.0. Commercial use is allowed if you keep the maker’s copyright and license notices. Changes you distribute must be shared under the same license.
- Hardware
- GPL-3.0
- Software
- GPL-3.0-or-later
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other humanoids.
Other humanoids in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| Bebo JrThis robotMeet-Bebo | Not documented | 4 of 6 | Yes, with creditHW GPL-3.0 · SW GPL-3.0-or-later | Raspberry PiMuJoCo | Not documented | — |
| MicrobanMarc Duclusaud | About $567Microban robot | 5 of 6 | NoHW CC BY-NC-SA 4.0 · SW GNU GPL v3 | Raspberry Pi | ActiveOct 30, 2026 | 645 |
| Asimov 1menloresearch | $20,000DIY Kit | 3 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW GPL-2.0 | MuJoCoRaspberry Pi | ActiveOct 30, 2026 | 1,373 |
| DropbearHyperspawn and Pointblank | Not documented | 2 of 6 | NoHW not documented · SW not documented | Isaac | ActiveOct 2, 2026 | 48 |
| This robotBebo Jr | Microban | Asimov 1 |
|---|---|---|
| Cost | ||
| Not documented | About $567 | $20,000 |
| Can I sell it? | ||
| Yes, with credit | No | Yes, with credit |
| Open files | ||
| 4 of 6 | 5 of 6 | 3 of 6 |
| Runs on | ||
| Raspberry Pi, MuJoCo | Raspberry Pi | MuJoCo, Raspberry Pi |
| Maintained | ||
| Not documented | ActiveOct 30, 2026 | ActiveOct 30, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit 71c5969. Websites and papers are listed with their review dates.
- 01README.md at 71c5969Reviewed Oct 30, 2026
- 02LICENSE at 71c5969Reviewed Oct 30, 2026