Star Arm 102
A 6+1 DoF robot arm platform with STEP and 3D-printing files, developed for teleoperation and LeRobot learning workflows.
Project documentation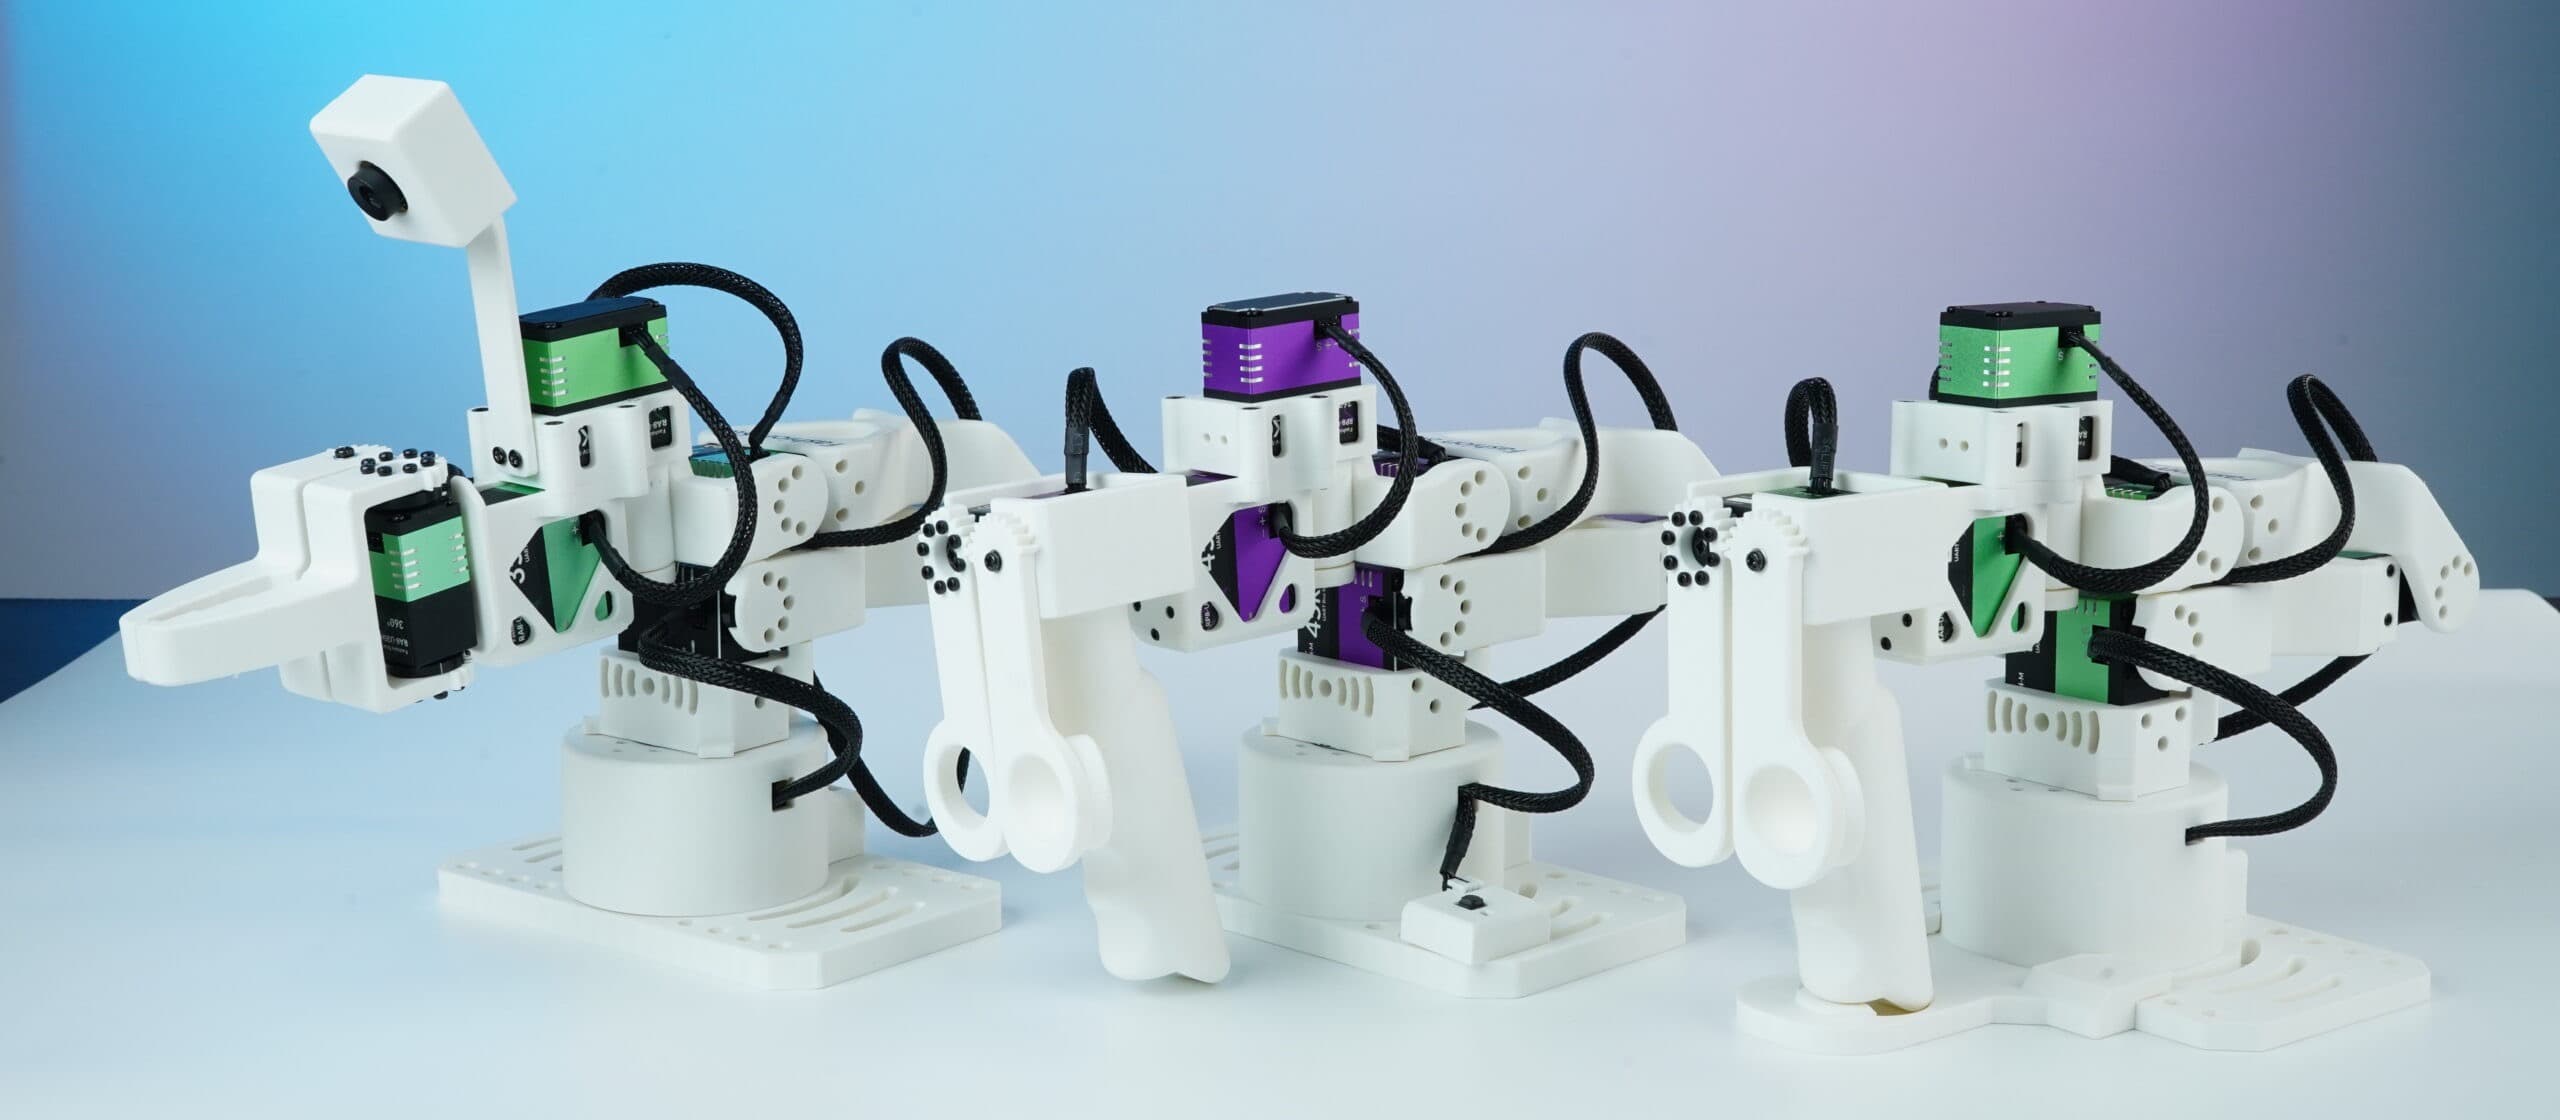
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Check firstCheck before commercial use
Hardware not documented · Software not documented. Licensing source
What’s open?
5 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: AvailableGuide: Available
PCB not documented. All six files
Is it maintained?
Active
Latest activity Oct 30, 2026 · main repo last commit Oct 30, 2026 · 171 commits in the last 52 weeks · 7 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
Star Arm 102 is a robot arm platform with LD, HD and FL models. Its hardware resources include STEP models, 3D-printing files, BOMs and URDF robot descriptions. The platform is developed for teleoperation, demonstration collection and LeRobot learning workflows.
Hardware
- Actuators
- Not documented Documentation
- Build
- 3D-printed · 3D-printing files are provided Documentation
- Degrees of freedom
- 6+1 README
- Reach
- 420 mm across the LD, HD and FL models README
- FL working payload
- 500 g README
Building it
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STEP assembly and part models are provided. | Not documented | step/ |
| Bill of materials | Available | Each model has its own files and inline BOM. | Not documented | README.md |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | Control code is included. | Not documented | lerobot/ |
| Simulation model | Available | URDF robot descriptions are provided. | Not documented | urdf/ |
| Assembly guide | Available | DIY assembly and calibration guide. | Not documented | README.md |
03 / Know before you build
Can you sell it?
Check firstCheck before commercial use
No license was found for the design files, so no reuse rights are granted. Ask the maker before building anything to sell.
- Hardware
- Not documented
- Software
- Not documented
04 / The upstream project
Is it maintained?
ActiveLatest activity Oct 30, 2026, 0 days before the snapshot
The main repository’s last commit was Oct 30, 2026.
- Stars
- 60
- Forks
- 16
- Contributors
- 7
- Latest release
- act-pick-v1.0.0 · Sep 30, 2026
Snapshot captured Oct 30, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other arms.
Other arms in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| Star Arm 102This robotFashion Star | Not documented | 5 of 6 | Check firstHW not documented · SW not documented | LeRobotROS 2Python | ActiveOct 30, 2026 | 60 |
| reBot Arm Base SeriesSeeed-Projects | Not documented | 4 of 6 | Yes, with creditHW CERN-OHL-W-2.0 · SW Apache-2.0 | ROS 1ROS 2LeRobot | ActiveOct 30, 2026 | 4,628 |
| SO-ARM 102Robonine | Not documented | 4 of 6 | YesHW CERN-OHL-P-2.0 · SW Apache-2.0 | LeRobot | ActiveOct 29, 2026 | 175 |
| Mini-ArmJonathan Shulgach | About $82Basic build | 5 of 6 | YesHW MPL-2.0 · SW Mozilla Public License 2.0 | ROS 2Raspberry PiPython | ActiveOct 23, 2026 | 14 |
| This robotStar Arm 102 | reBot Arm Base Series | SO-ARM 102 |
|---|---|---|
| Cost | ||
| Not documented | Not documented | Not documented |
| Can I sell it? | ||
| Check first | Yes, with credit | Yes |
| Open files | ||
| 5 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| LeRobot, ROS 2, Python | ROS 1, ROS 2, LeRobot, Isaac, Python | LeRobot |
| Maintained | ||
| ActiveOct 30, 2026 | ActiveOct 30, 2026 | ActiveOct 29, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit f2e04fb. Websites and papers are listed with their review dates.
- 01README.md at f2e04fbReviewed Oct 30, 2026
- 02LICENSE.md at f2e04fbReviewed Oct 30, 2026
- 03hardware/README.md at f2e04fbReviewed Oct 30, 2026
- 04docs/diy-assembly/README.md at f2e04fbReviewed Oct 30, 2026