UMI-3D
A handheld gripper with a LiDAR and camera, using 3D-printed mounts and soft fingers.
Project documentation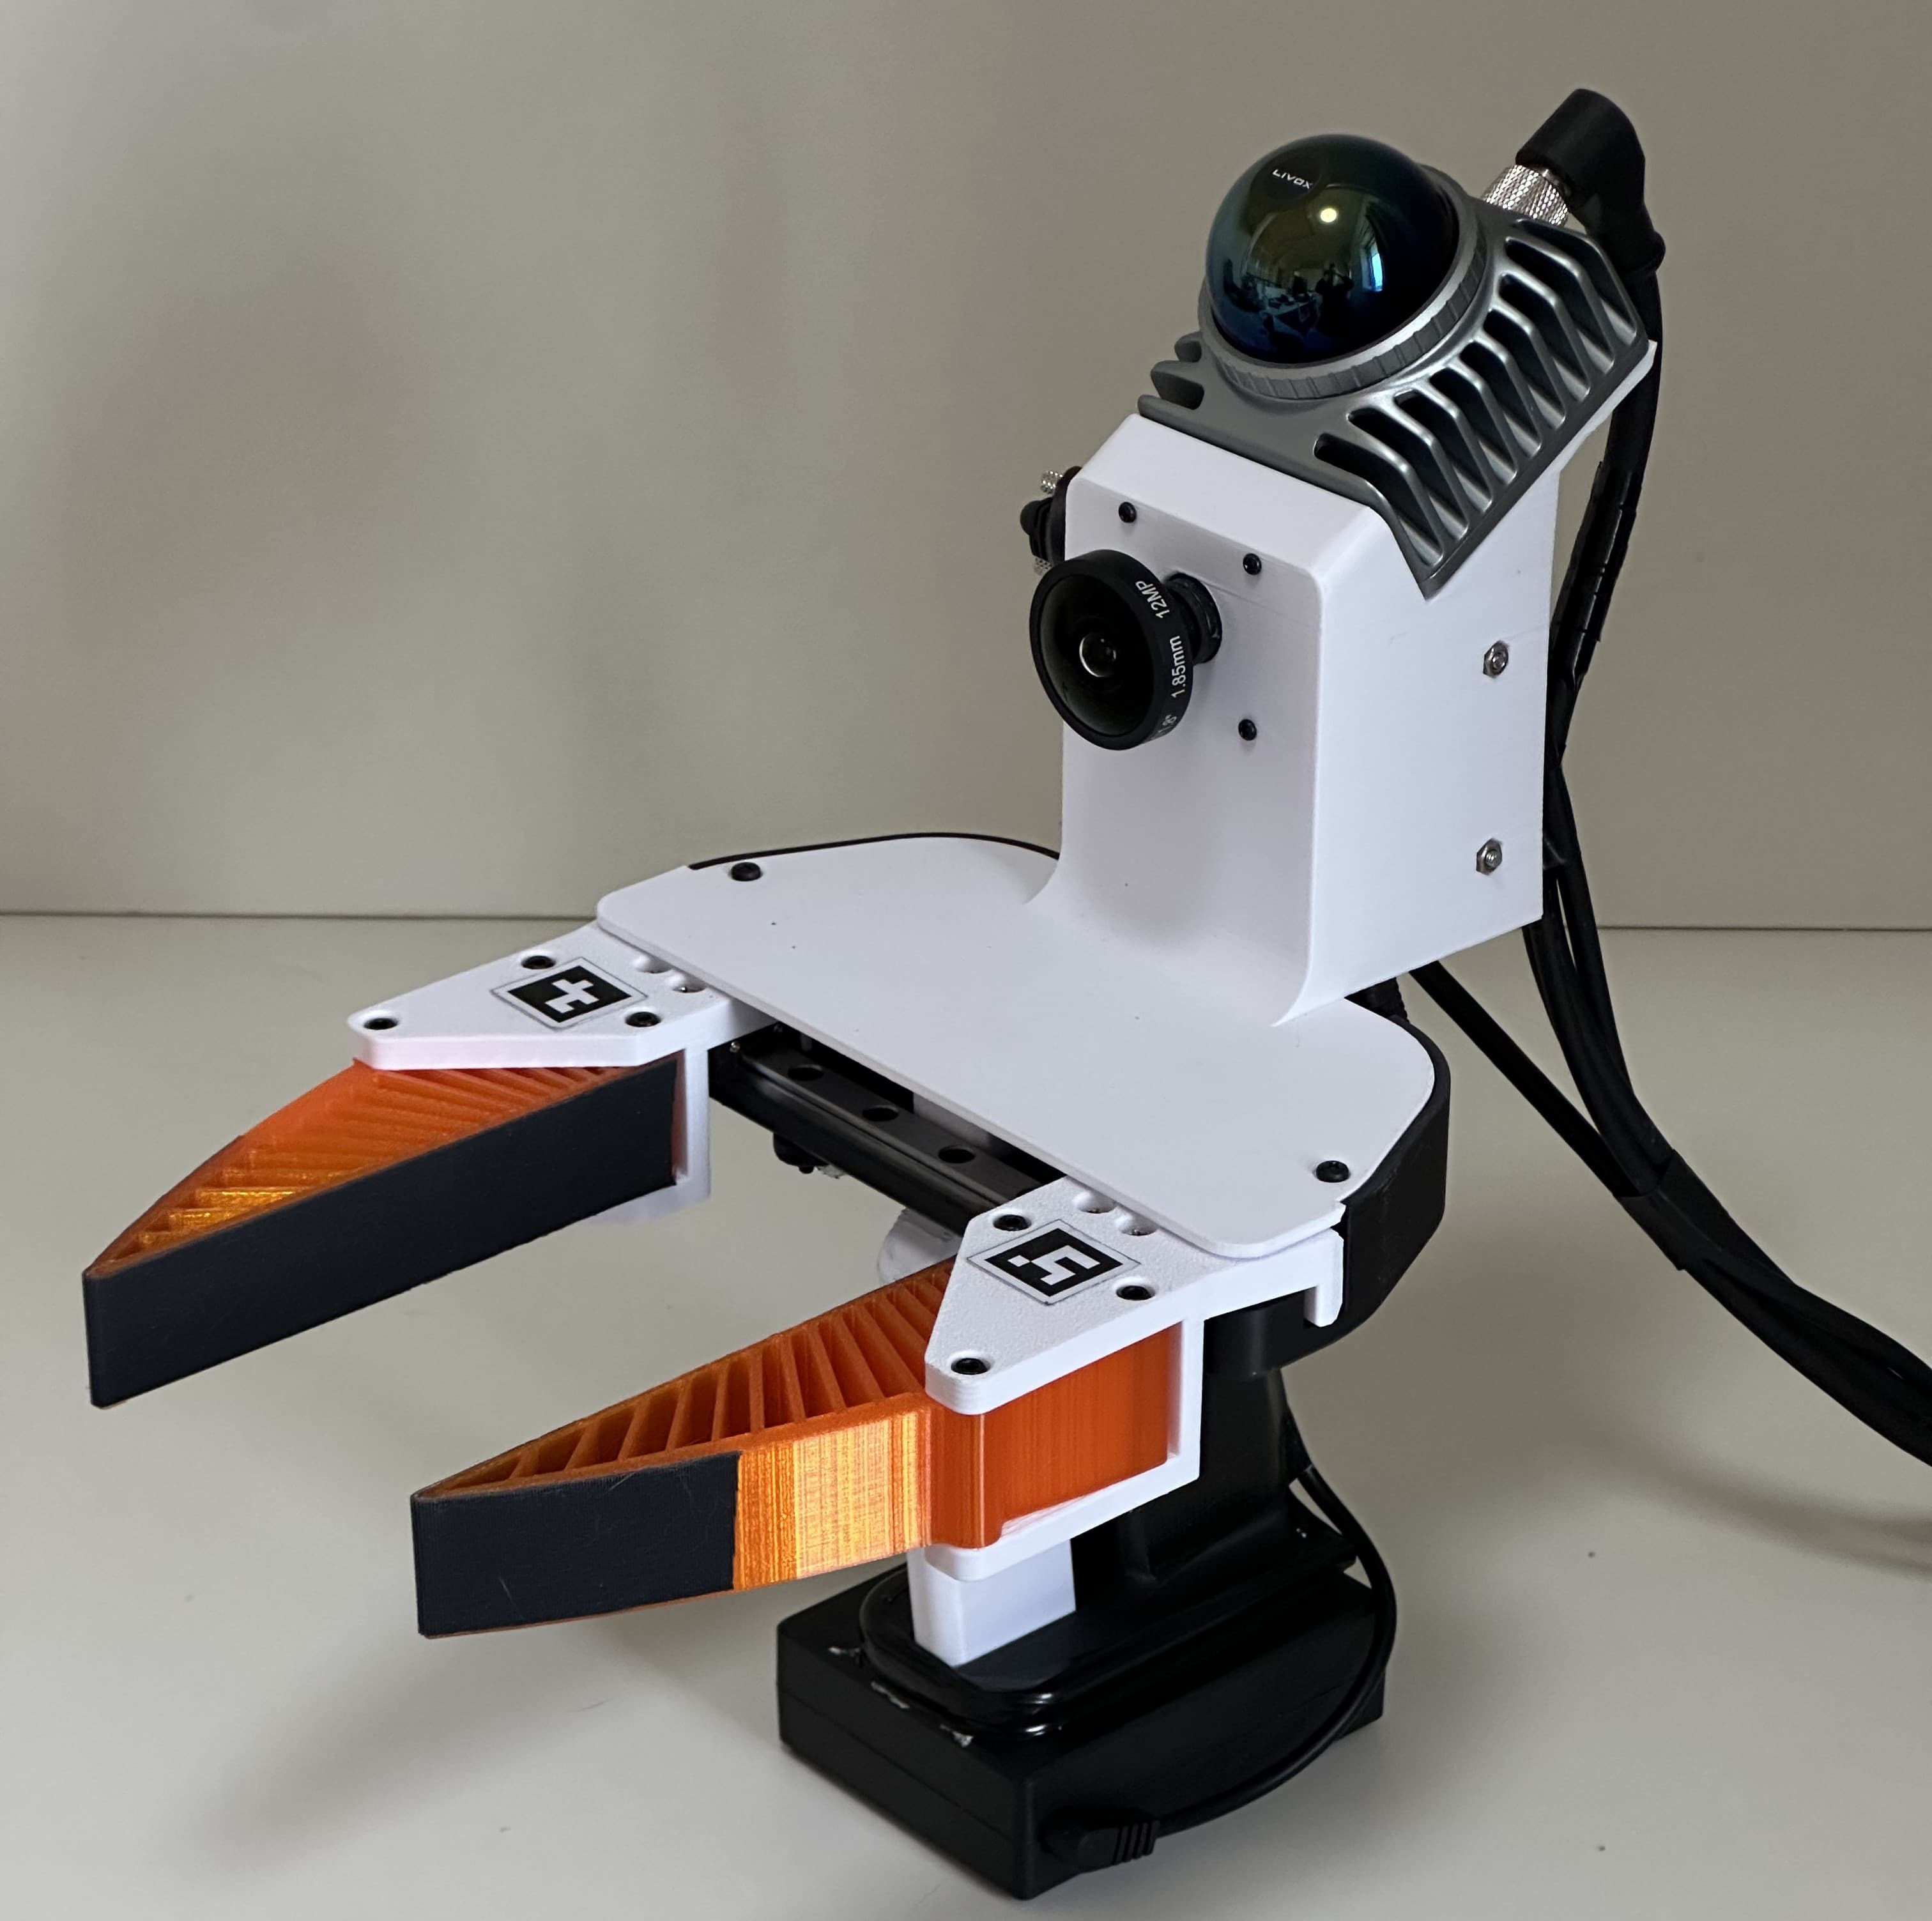
Before you build
Five answers, each linked to its source
What does it cost?
About CN¥5,000target total cost
The target total cost is subject to actual purchase. README
Can I sell what I build?
YesCommercial use OK
Hardware Apache-2.0 · Software Apache-2.0. Licensing source
What’s open?
4 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: Not documentedGuide: Available
PCB, sim not documented. All six files
Is it maintained?
Quiet
Latest activity Jun 24, 2026 · main repo last commit Apr 16, 2026 · 20 commits in the last 52 weeks · 1 contributors Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
UMI-3D is a handheld gripper fitted with a LiDAR and camera. Its listed mechanical parts include a PLA-printed gripper mount, TPU 95A soft fingers and a 150mm linear module. The sensing setup records LiDAR data and camera images for SLAM, sensor calibration, data processing and policy training.
Hardware
- Actuators
- Not documented Documentation
- Build
- 3D-printed · printable parts in the repository Documentation
- LiDAR
- Livox MID-360/MID-360S README
- Camera
- Hikrobot MV-CB013-A0UC-S README
- Linear module
- 150mm MG9NC Linear Module README
Building it
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | A public Onshape CAD document is linked. | Not documented | cad.onshape.com |
| Bill of materials | Available | The README includes a bill of materials. | Not documented | README.md |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | ROS drivers and helper scripts are provided. | Not documented | umi_3d_ros_driver/ |
| Simulation model | Not documented | Not documented | Not documented | No source found |
| Assembly guide | Available | The README is a hardware building guide. | Not documented | README.md |
03 / Know before you build
Can you sell it?
YesCommercial use OK
The whole repository, design files included, is Apache-2.0. You can build, modify and sell robots based on it, as long as you keep the license and copyright notices.
- Hardware
- Apache-2.0
- Software
- Apache-2.0
04 / The upstream project
Is it maintained?
QuietLatest activity Jun 24, 2026, 128 days before the snapshot
The main repository’s last commit was Apr 16, 2026.
- Stars
- 131
- Forks
- 10
- Contributors
- 1
- Latest release
- v0.1.0 · Jun 24, 2026
Snapshot captured Oct 30, 2026. Recorded figures, not live metrics. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
About CN¥5,000
target total cost
The target total cost is subject to actual purchase.
READMEKit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other hands & grippers.
The three hands & grippers with the closest documented maker’s cost. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| UMI-3DThis robotPhysical-Intelligence-Laboratory | About CN¥5,000target total cost | 4 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ROS 1 | QuietJun 24, 2026 | 131 |
| Aero Hand OpenChestnut Robotics | $314complete kit | 6 of 6 | NoHW CC BY-NC-SA 4.0 · SW Apache-2.0 | ROS 2MuJoCoPython | ActiveSep 15, 2026 | 1,054 |
| AmazingHandPollen Robotics | Under €200hand, before controller | 5 of 6 | Yes, with creditHW CC BY 4.0 · SW Apache-2.0 | PythonArduinoMuJoCo | QuietApr 3, 2026 | 2,462 |
| YAM-UMIYosub Shin | About $79per gripper | 3 of 6 | YesHW MIT · SW MIT | Not documented | Not documented | — |
| This robotUMI-3D | Aero Hand Open | AmazingHand |
|---|---|---|
| Cost | ||
| About CN¥5,000 | $314 | Under €200 |
| Can I sell it? | ||
| Yes | No | Yes, with credit |
| Open files | ||
| 4 of 6 | 6 of 6 | 5 of 6 |
| Runs on | ||
| ROS 1 | ROS 2, MuJoCo, Python, ESP32 | Python, Arduino, MuJoCo |
| Maintained | ||
| QuietJun 24, 2026 | ActiveSep 15, 2026 | QuietApr 3, 2026 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit fb4c5ef. Websites and papers are listed with their review dates.
- 01README.md at fb4c5efReviewed Oct 30, 2026
- 02LICENSE at fb4c5efReviewed Oct 30, 2026