Open source robot for liquid handing and serial multiplexing fluorescence microscopy
A gantry liquid-handling robot with three tips for moving reagent, buffer, and waste during serial multiplexing microscopy.
Project documentation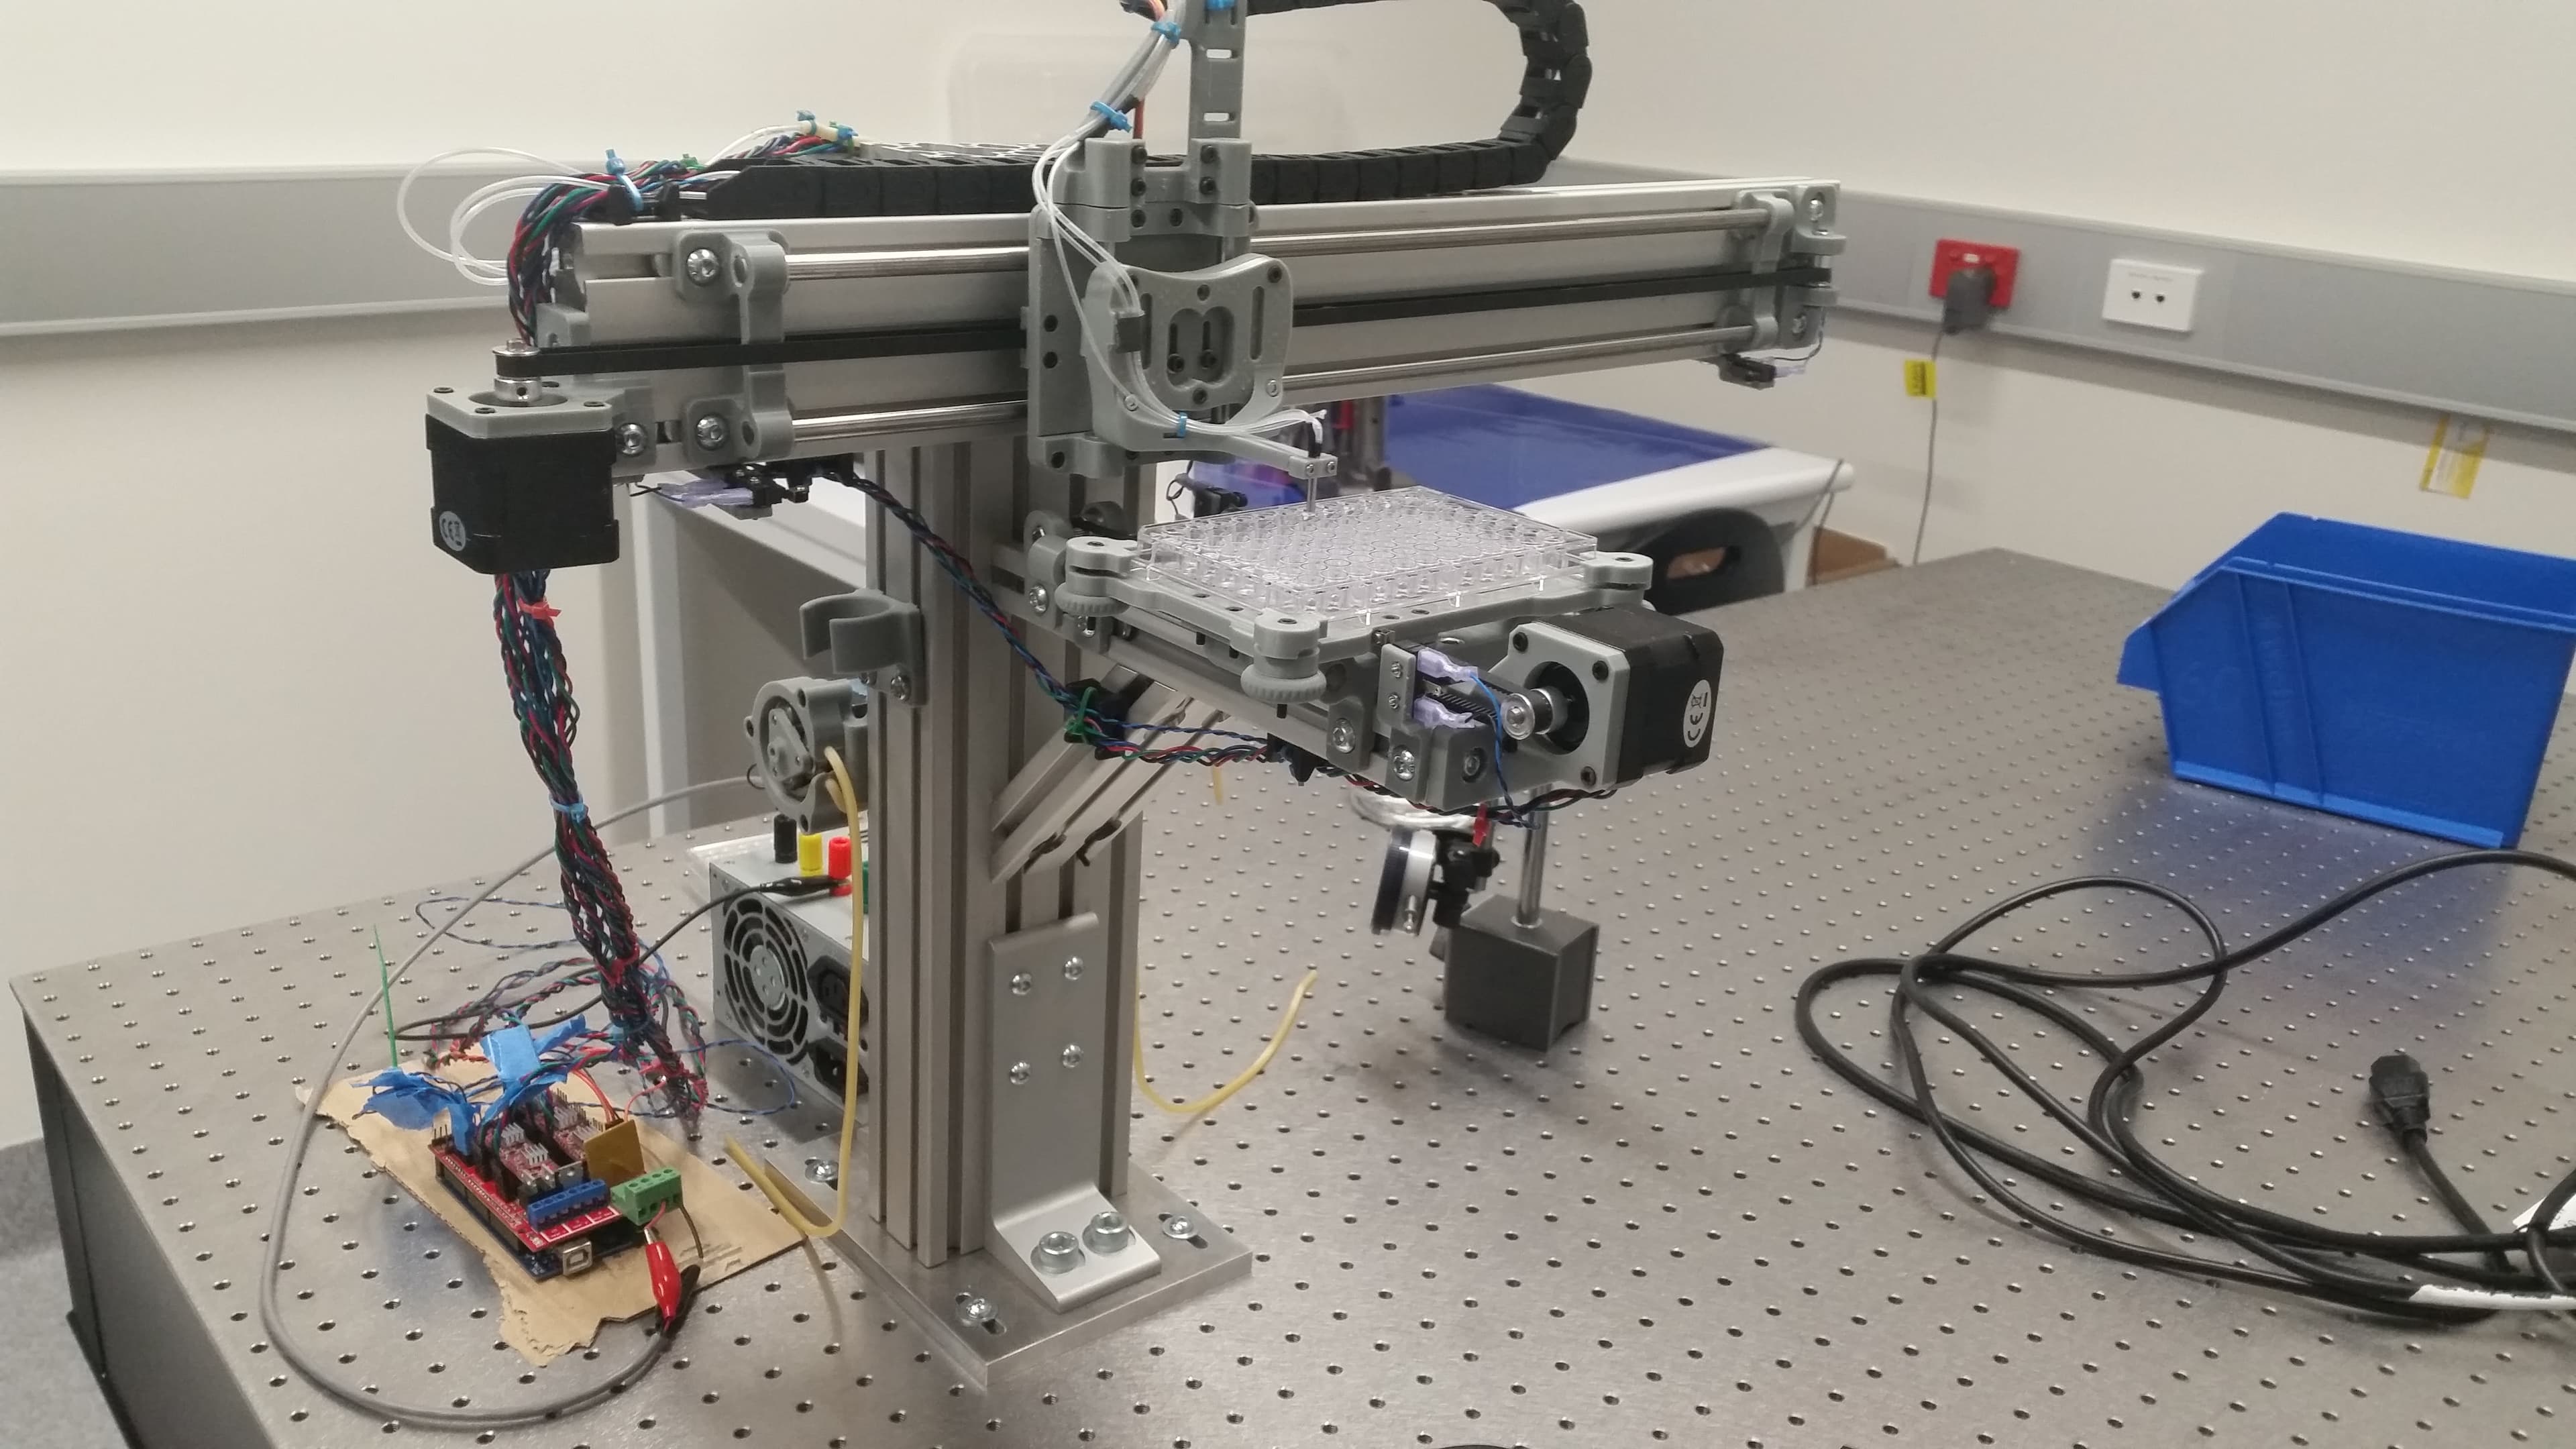
Before you build
Five answers, each linked to its source
What does it cost?
Not documented
No cost in the reviewed sources.
Can I sell what I build?
Check firstCheck before commercial use
Hardware not documented · Software not documented. Licensing source
What’s open?
4 of 6CAD: AvailableBOM: AvailablePCB: Not documentedCode: AvailableSim: Not documentedGuide: Available
PCB, sim not documented. All six files
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
This gantry liquid-handling robot moves a three-tip head between a reagent well plate and a sample on a microscope. Its pumps draw and dispense reagent, deliver buffer, and withdraw waste for repeated labelling and washing steps. The design uses 3D-printed parts and T-slot aluminum, with STEP and STL files provided for building the hardware.
Hardware
- Actuators
- Not documented Documentation
- Build
- Mixed · T-slot aluminum · 3D-printed parts Documentation
- Liquid-handling head
- Three separate tips README
- Carrier-axis distance
- Approximately 450 mm README
Building it
- Printed parts
- Printed on a Zortrax M200 filament printer with Ultra-T filament. Printing and assembly notes.txt
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | STEP assembly files and STL files for 3D printing. | Not documented | STEP Files/ |
| Bill of materials | Available | Bill of Materials for items to be purchased for the build. | Not documented | BillofMaterials.xlsx |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Available | Marlin configuration files and MATLAB PC-side code. | Not documented | Code/ |
| Simulation model | Not documented | Not documented | Not documented | No source found |
| Assembly guide | Available | Printing and assembly notes. | Not documented | Printing and assembly notes.txt |
03 / Know before you build
Can you sell it?
Check firstCheck before commercial use
No license was found for the design files, so no reuse rights are granted. Ask the maker before building anything to sell.
- Hardware
- Not documented
- Software
- Not documented
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
Not documented
No cost in the reviewed sources.
Kit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other other robots.
Other other robots in the directory, most recently active first. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| Open source robot for liquid handing and serial multiplexing fluorescence microscopyThis robotPRNicovich | Not documented | 4 of 6 | Check firstHW not documented · SW not documented | Arduino | Not documented | — |
| openBrushographDominik Mahnic | Not documented | 1 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW not documented | ESP32Arduino | ActiveOct 15, 2026 | 28 |
| Antagonistic Tendon Driven Continuum RobotChristian Marzi | Not documented | 1 of 6 | Yes, with creditHW CERN-OHL-W-2.0 · SW CERN-OHL-W-2.0 | Arduino | Not documented | — |
| Aria Art Plottergustavomayoral | Not documented | 4 of 6 | Yes, with creditHW CERN-OHL-S-2.0 · SW GPL-3.0 | ArduinoPython | Not documented | — |
| This robotOpen source robot for liquid handing and serial multiplexing fluorescence microscopy | openBrushograph | Antagonistic Tendon Driven Continuum Robot |
|---|---|---|
| Cost | ||
| Not documented | Not documented | Not documented |
| Can I sell it? | ||
| Check first | Yes, with credit | Yes, with credit |
| Open files | ||
| 4 of 6 | 1 of 6 | 1 of 6 |
| Runs on | ||
| Arduino | ESP32, Arduino | Arduino |
| Maintained | ||
| Not documented | ActiveOct 15, 2026 | Not documented |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit e6a73ff. Websites and papers are listed with their review dates.
- 01README.md at e6a73ffReviewed Nov 1, 2026
- 02STL Files/Printing and assembly notes.txt at e6a73ffReviewed Nov 1, 2026