OpenBMP
A bimanual platform of two modular MOAH arms, each with four axially driven joints and one tendon-driven joint.
Project documentation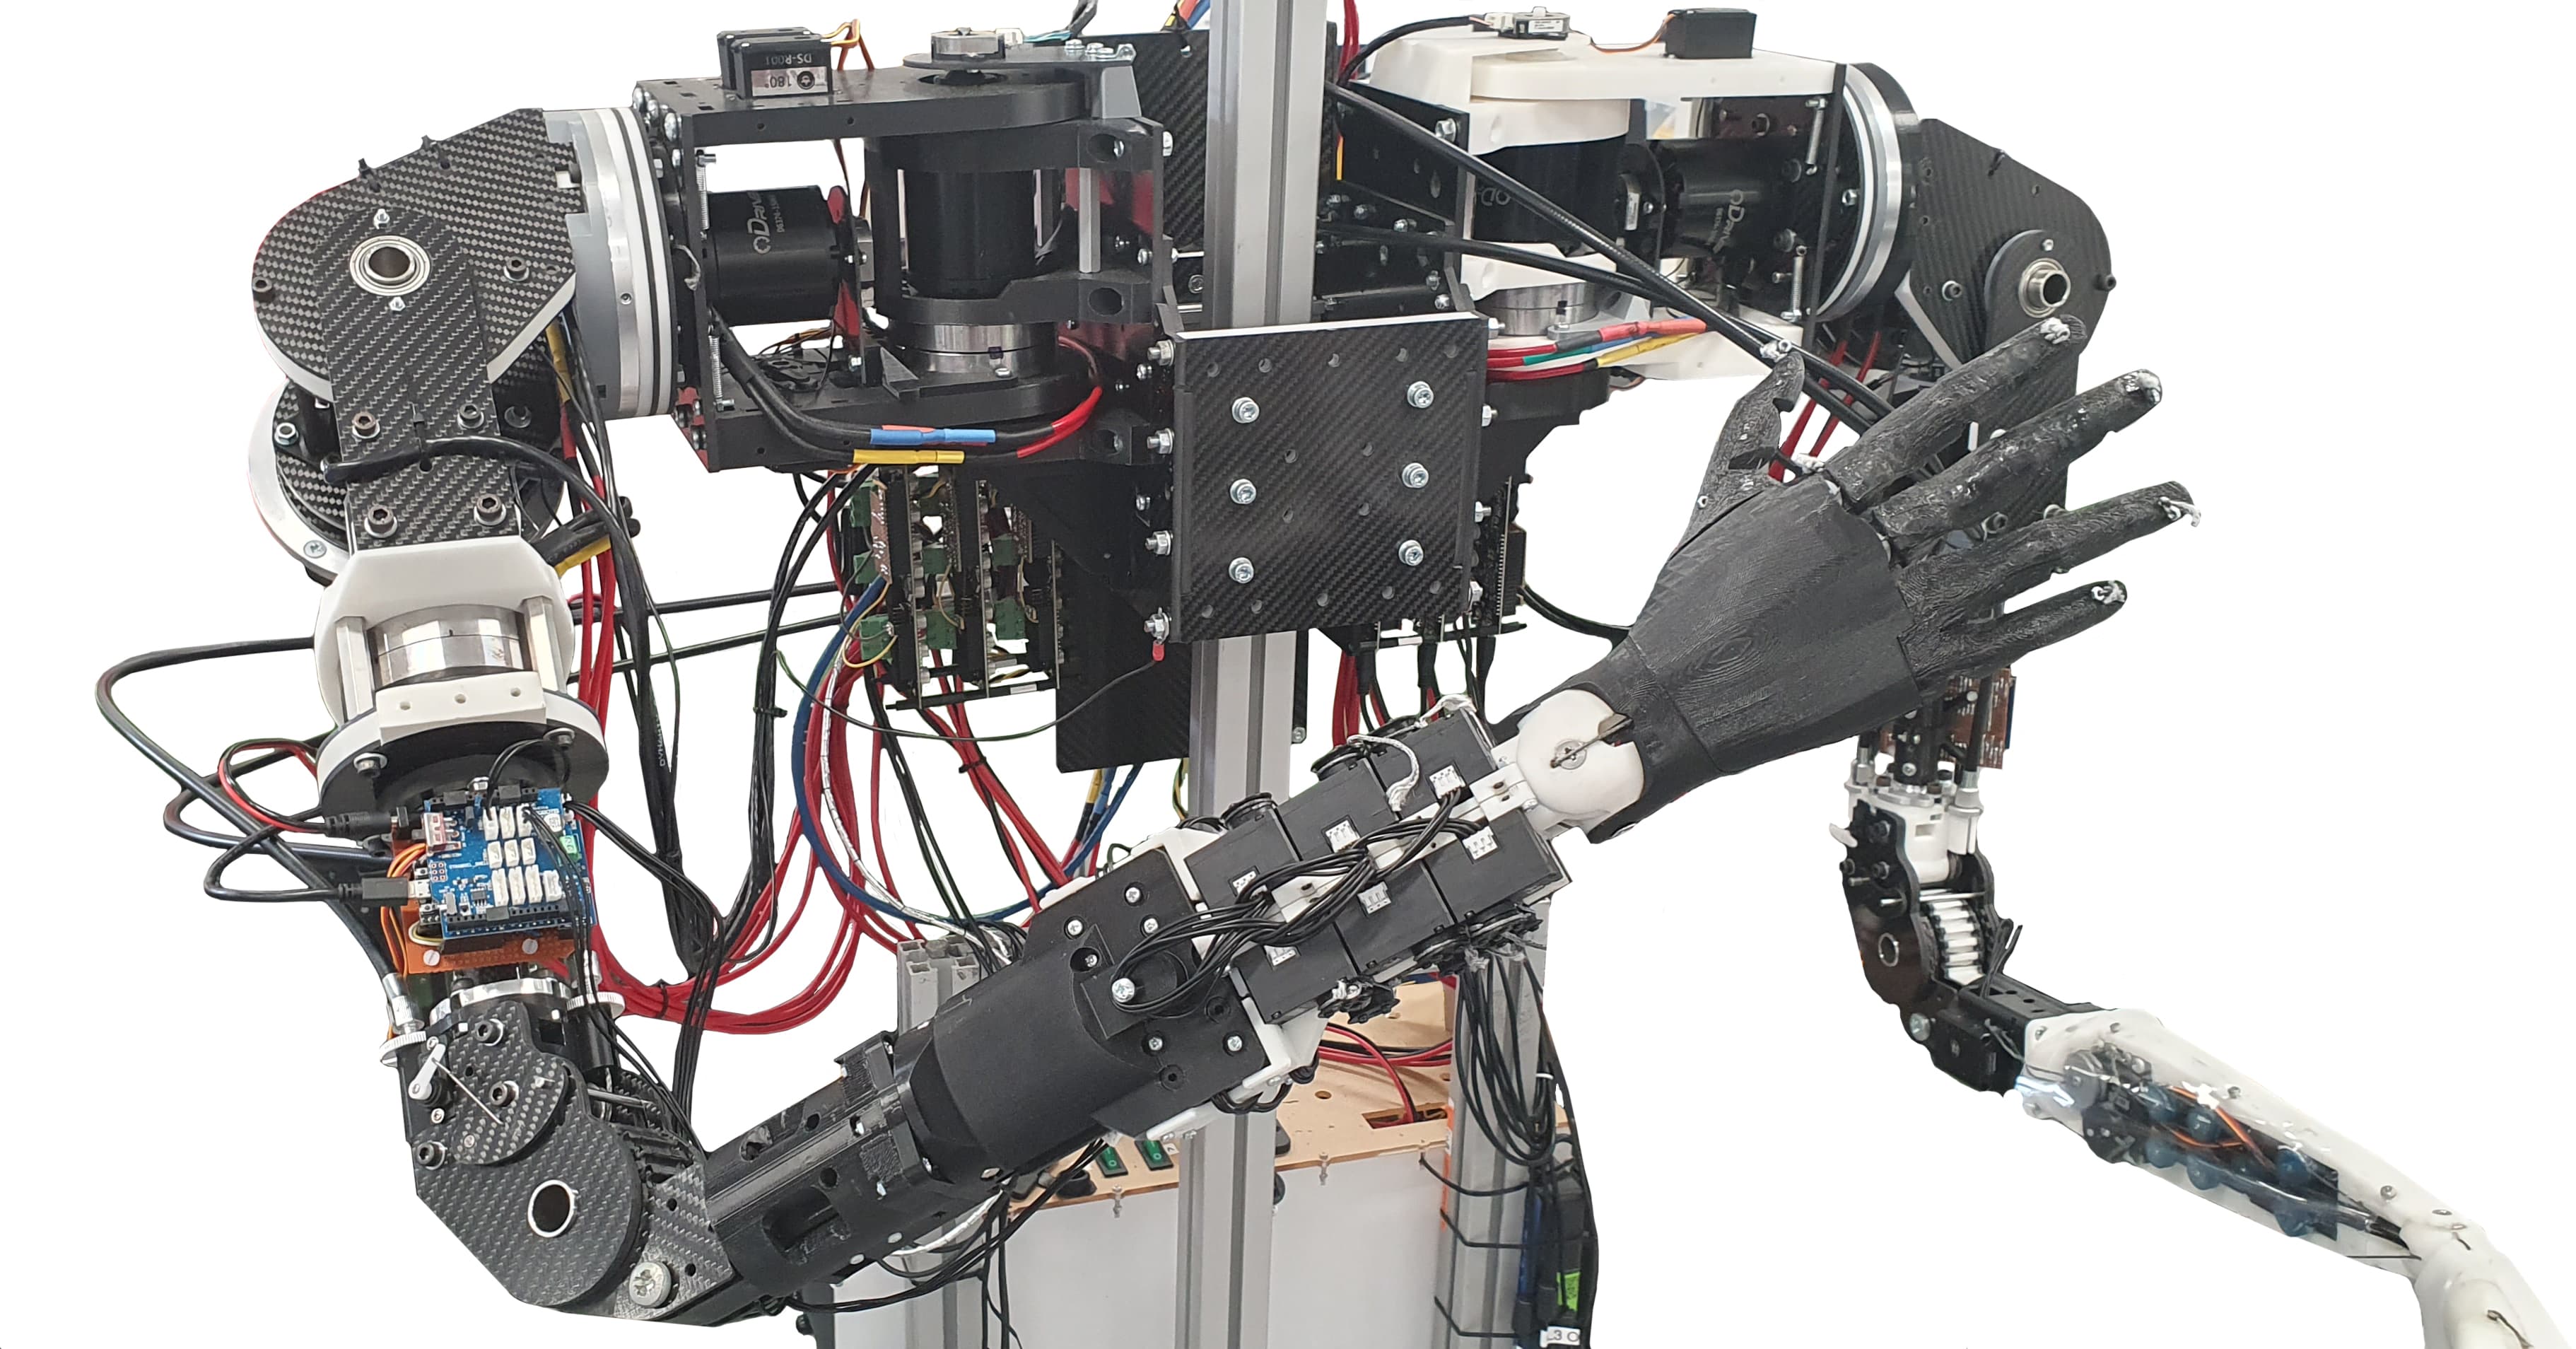
Before you build
Five answers, each linked to its source
What does it cost?
About $11,600Bimanual robot arm platform (without forearm module)
The README lists this as the approximate hardware cost for the bimanual robot arm platform without a forearm module. README
Can I sell what I build?
NoNon-commercial hardware
Hardware Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0) · Software not documented. Licensing source
What’s open?
1 of 6CAD: AvailableBOM: PartialPCB: Not documentedCode: PartialSim: PartialGuide: Not documented
BOM, code, sim partial · PCB, guide not documented. All six files
What does it run on?
Simulation: The main software package is described as supporting simulation and visualization. Software
Is it maintained?
Not documented
No activity snapshot yet. Activity
01 / Under the shell
The specifications.
Hardware, build and software on one sheet. Every fact links to where we found it.
OpenBMP is a bimanual manipulation platform made from two modular MOAH arms. Each arm is described as a 5 DoF mixed-drive manipulator with four axially driven joints and one tendon-driven joint. The platform uses 3D-printed PLA parts reinforced with carbon fibre composite plates and is intended for education and research into bimanual manipulation systems and experimental actuation or kinematic configurations.
Hardware
- Actuators
- Not documented Documentation
- Build
- Mixed · PLA · FDM; carbon fibre plates · waterjet cutting Documentation
- Arm joints
- 5 DoF upper, with four axially driven joints and one tendon-driven joint in each arm README
- Single arm weight
- 12.4 kg README
Building it
- Structure
- Most of the structure is designed to be 3D printed, with reinforcing parts cut from carbon fibre plates. README.md
- Original manufacturing
- The original version used Prusa mk3 printers and standard Esun filaments; carbon fibre plates were cut using a desktop WAZER water jet cutter. README.md
- Custom components
- Some components require machining capabilities. README.md
Software & simulation
- Control software
- The repository includes an interface for joint control, marked WIP. README
02 / The files behind the robot
What’s open.
Six parts of the build, each checked separately. Gaps stay visible.
| Part | Status | What’s there | License | Source |
|---|---|---|---|---|
| CAD | Available | CAD design files for manufacturing, including assembled robot CAD. | Not documented | CAD/ |
| Bill of materials | Partial | The Bill of Materials document lists required components for assembling the bimanual robot. | Not documented | Bill_of_Materials.xlsx |
| Electronics | Not documented | Not documented | Not documented | No source found |
| Code | Partial | Software includes an interface for joint control; the README marks it WIP. | Not documented | Software/ |
| Simulation model | Partial | The main software package is described as supporting simulation and visualization. | Not documented | urdf/ |
| Assembly guide | Not documented | Not documented | Not documented | No source found |
03 / Know before you build
Can you sell it?
NoNon-commercial hardware
The design files are Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0), which restricts them to non-commercial use. Selling robots or parts made from the design needs the maker’s permission.
- Hardware
- Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0)
- Software
- Not documented
04 / The upstream project
Is it maintained?
Not documentedRepository activity is not documented
Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer.
05 / Parts & kits
A head start.
Maker-listed sellers only. No affiliate links or paid placement.
MAKER’S COST
About $11,600
Bimanual robot arm platform (without forearm module)
The README lists this as the approximate hardware cost for the bimanual robot arm platform without a forearm module.
READMEKit availability is not documented in our reviewed sources.
06 / Side by side
Compare with other arms.
The three arms with the closest documented maker’s cost. Same sources, same rules.
| Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|
| OpenBMPThis robotNew Dexterity | About $11,600Bimanual robot arm platform (without forearm module) | 1 of 6 | NoHW Creative Commons Attribution-NonCommercial 4.0 International (CC BY-NC 4.0) · SW not documented | ROS 1Raspberry PiESP32 | Not documented | — |
| OpenEAI-Armeai-yeslab | About CN¥5,500documented manufacturing cost | 4 of 6 | YesHW BSD-3-Clause · SW BSD-3-Clause | ROS 2Python | ActiveOct 17, 2026 | 141 |
| Ark_BotRobotics-Ark | £348.12Amazon total | 4 of 6 | YesHW MIT · SW MIT | Python | DormantOct 13, 2025 | 32 |
| ALTO 3D Printed 6 Axis Robotic Arm (WIP)liaochikon | About $400total for the robot | 3 of 6 | YesHW MIT · SW MIT | Python | Not documented | — |
| This robotOpenBMP | OpenEAI-Arm | Ark_Bot |
|---|---|---|
| Cost | ||
| About $11,600 | About CN¥5,500 | £348.12 |
| Can I sell it? | ||
| No | Yes | Yes |
| Open files | ||
| 1 of 6 | 4 of 6 | 4 of 6 |
| Runs on | ||
| ROS 1, Raspberry Pi, ESP32, Arduino | ROS 2, Python | Python |
| Maintained | ||
| Not documented | ActiveOct 17, 2026 | DormantOct 13, 2025 |
Upkeep is measured against each robot’s own snapshot. Costs keep the maker’s scope, so check what each figure covers.
See them in the table07 / Follow the evidence
Open books.
Repository files are pinned to commit 696125c. Websites and papers are listed with their review dates.
- 01README.md at 696125cReviewed Oct 30, 2026
- 02License.md at 696125cReviewed Oct 30, 2026
- 03Assembly Guide/README.md at 696125cReviewed Oct 30, 2026