01 / CAD
The shape of things.
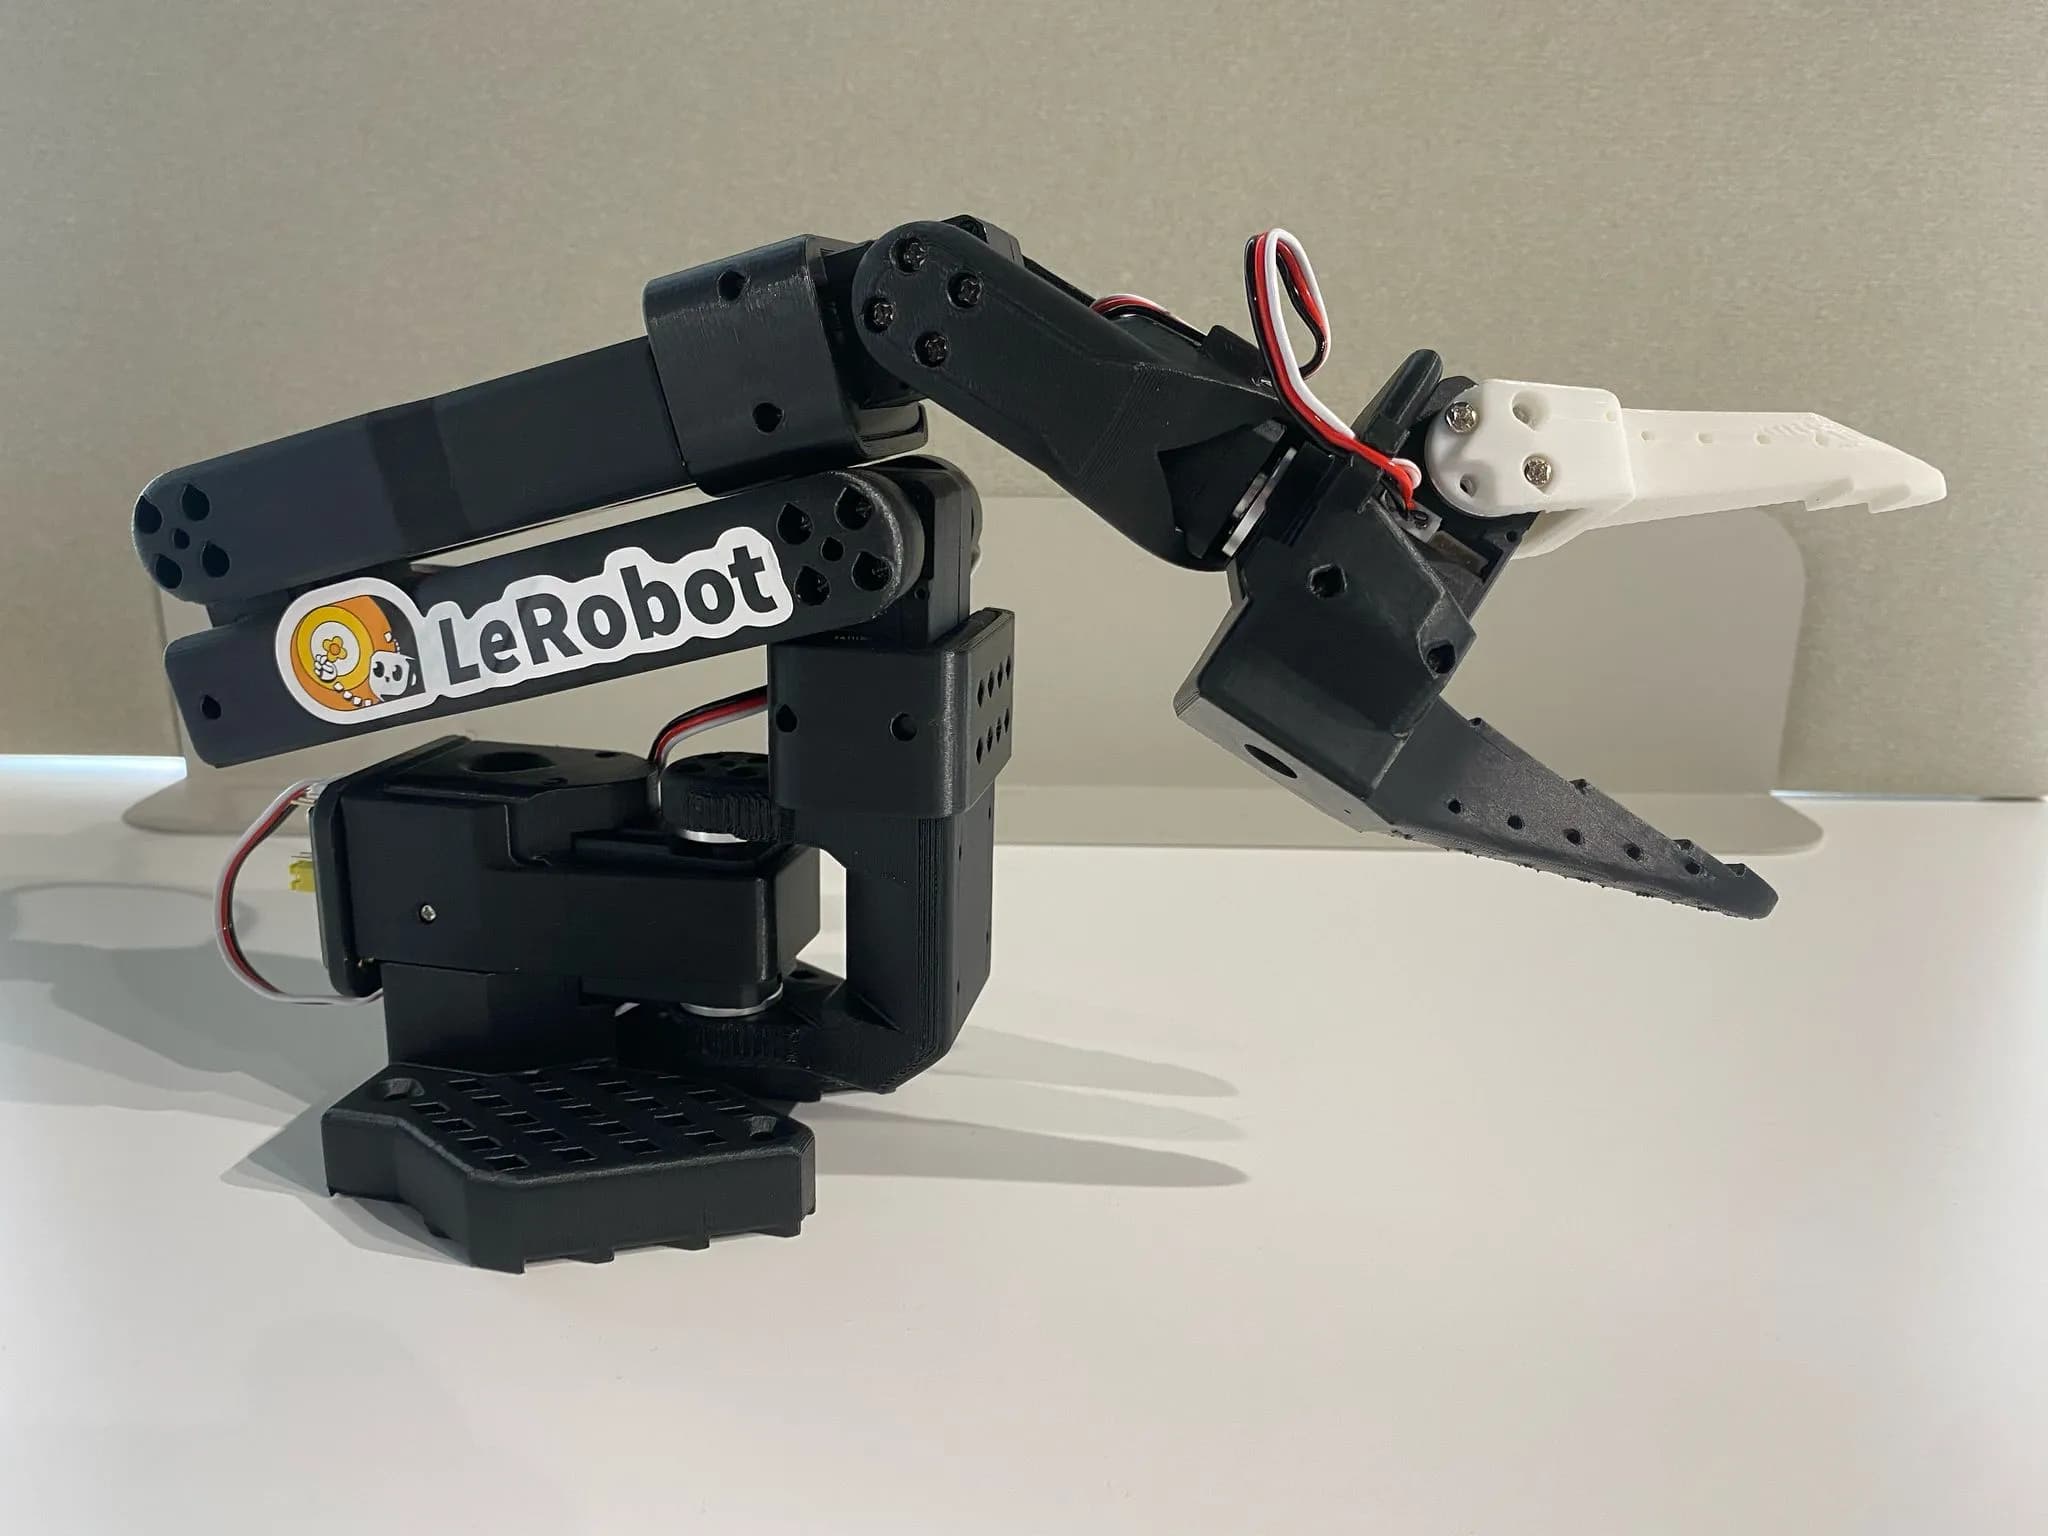
Design files and printable parts. See what you can make, modify, and put together.
THE OPEN ROBOT DIRECTORY
Find your next robot to build. Discover open-source hardware, from the first printed part to the code that makes it move.
 LESS SCROLLING.
01 THE COLLECTION
Small hands. Big ideas. A rover for the long way home.
There’s a whole world of hardware to make your own.
| Compare | Robot | Cost | Open files | Can I sell it? | Runs on | Maintained | Stars |
|---|---|---|---|---|---|---|---|
| Aero Hand OpenChestnut Robotics | $314complete kit | 6 of 6 | NoHW CC BY-NC-SA 4.0 · SW Apache-2.0 | ROS 2MuJoCo+2 | ActiveSep 15, 2026 | 1,054 | |
| AmazingHandPollen Robotics | Under €200hand, before controller | 5 of 6 | Yes, with creditHW CC BY 4.0 · SW Apache-2.0 | PythonArduino+1 | QuietApr 3, 2026 | 2,462 | |
| GaiaHandStella-robot | Not documented | 3 of 6 | YesHW MIT · SW MIT | Python | Not documented | — | |
| Hands-on Tutorial: 3D Tactile Sensor Integration in Robotic Fingers for Smart ManipulationMilan Amighi, Constantin Scholz, and Bram Vanderborght (Brubotics – VUB & imec) | Not documented | 2 of 6 | Check firstHW not documented · SW not documented | ROS 2Python+1 | ActiveSep 4, 2026 | 7 | |
| Pinc'Openpollen-robotics | About €25standalone PincOpen gripper BOM | 3 of 6 | Yes, with creditHW CC BY-SA 4.0 · SW CC-BY-SA-4.0 | LeRobotPython | Not documented | — | |
| SROIZenan Sheng, Linsheng Hou & Zhenghao Fei — Zhejiang University | Not documented | 3 of 6 | Check firstHW not documented · SW not documented | Not documented | Not documented | — | |
| SSG48 adaptive electric gripperSource-Robotics | Not documented | 4 of 6 | YesHW Apache 2.0 · SW Apache-2.0 | ROS 2Python | ActiveSep 27, 2026 | 184 | |
| UMI-3DPhysical-Intelligence-Laboratory | About CN¥5,000target total cost | 4 of 6 | YesHW Apache-2.0 · SW Apache-2.0 | ROS 1 | QuietJun 24, 2026 | 131 | |
| YAM-UMIYosub Shin | About $79per gripper | 3 of 6 | YesHW MIT · SW MIT | Not documented | Not documented | — | |
| YUBI GripperFrontier Research Center, Toyota Motor Corporation | Not documented | 3 of 6 | Yes, with creditHW CERN Open Hardware Licence Version 2 - Weakly Reciprocal (CERN-OHL-W v2) · SW CERN-OHL-W-2.0 | Not documented | ActiveSep 21, 2026 | 188 |
Costs are the maker’s documented figures, with their original scope. Stars are recorded GitHub snapshots, never a quality score. Active: activity within 90 days of the snapshot. Quiet: within a year. Dormant: longer. Read between the files
02 READ BETWEEN THE FILES
A public repository is a start. A buildable robot takes more. We look at six parts of every project, so you know what’s there before you get your hands busy.
Design files and printable parts. See what you can make, modify, and put together.
A bill of materials. The shopping list behind the build, with costs where documented.
Circuit designs, boards, and wiring. Custom hardware or off-the-shelf components.
The software that brings it to life. Check the stack before you start building.
A digital model to test, train, and explore before the hardware meets the real world.
Assembly instructions. Because a folder full of files isn’t the same as a finished robot.
Those are different questions. Hardware and software can carry different licenses. Every listing explains what’s available and what the documented licenses allow. If we don’t know, we say so.